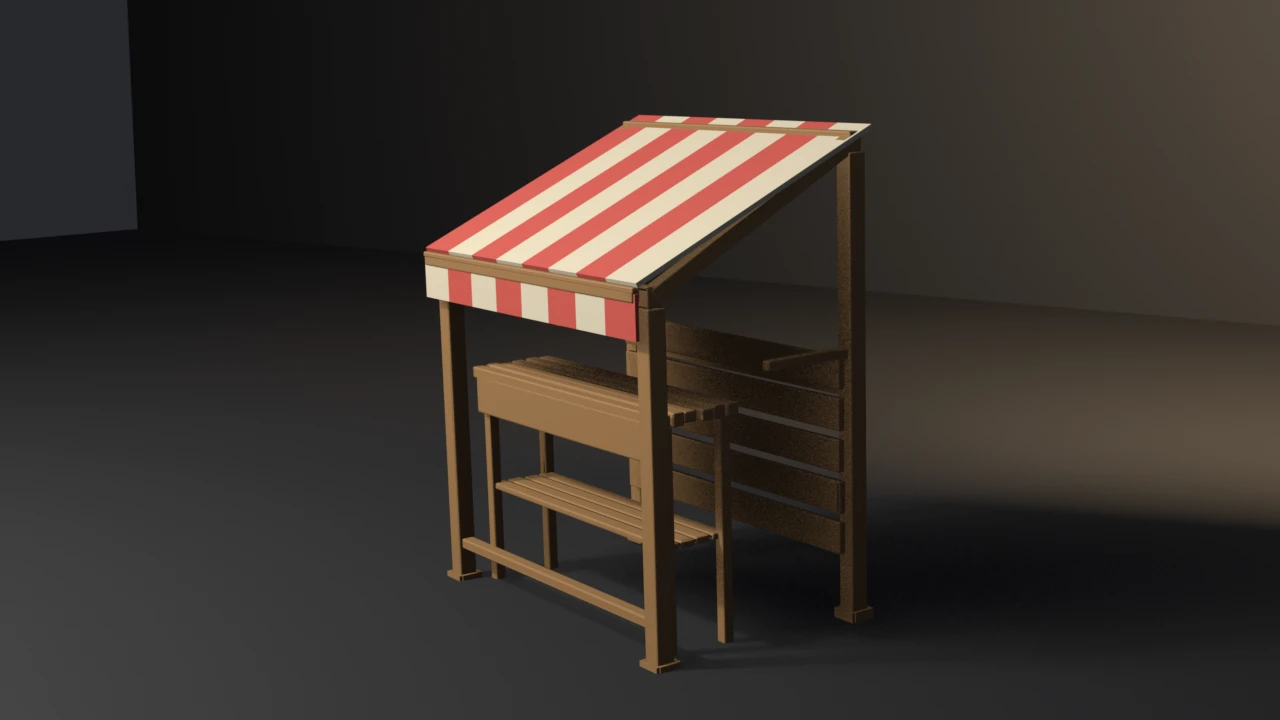
Rendered headless by the example itself — click to zoom.
blender --background --python showcase/market-stall/market_stall.py --
A showcase piece, not an example. Procedural timber stall (corner posts with wrap plinths, slatted counter and shelf, back-wall planks, side braces that sit in the post bay, striped awning with a front roller and hanging valance) then the shipped pipeline: unique-cell UVs, Cycles high-to-low normal bake, LOD chain, convex collider, Unity glTF export.
The old piece used capped foot cubes coplanar with the post bottoms and counter-leg pads coplanar with the legs, which z-fought at Z=0. Wrap plates stand off the post; counter legs go to Z=0 without a second bottom face.
It asserts budget conformance of the generated result. It does not witness an API contract. "It rendered without error" is not a check.
Composes skills mesh-editing-and-bmesh, bake-high-to-low, depsgraph-and-evaluated-data, engine-export-presets, and snippets bake_normal_high_to_low.py, setup_bake_target_image.py, lod_chain.py / decimate_to_budget.py, convex_hull_collider.py, export_preset_unity.py (helpers copied, not imported as a package).
Budgets
Declared as named constants; every gate recomputes from the mesh, materials, UVs, evaluated LOD, collider, or export file.
| Axis | Declared | Measured (4.5.11 / 5.1.2 / 5.2.1) | | --- | --- | --- | | Base triangles | 3900–5200 | 4324 / 4324 / 4324 | | LOD1 ratio | 0.32–0.62 of base | 0.5000 / 0.5000 / 0.5000 | | LOD2 ratio | 0.10–0.35 of base | 0.2197 / 0.2197 / 0.2197 | | Materials | exactly 3 distinct; ≥16 faces per stripe slot | 3 slots; 34 / 34 stripe faces | | UVs | in 0..1, AABB overlap ≤ 1e-5 | in range, overlap 0 | | Outer AABB | (1.389, 1.011, 1.740) m ± 0.01 | (1.3892, 1.0107, 1.7402), zmin 0 | | Collider tris | ≤ 80 | 58 | | Export | written, size > 0 | 312752 / 312752 / 312728 bytes |
Hygiene
Recomputed from the generated mesh, not asserted about the script.
| Axis | Declared | Measured (all three) | | --- | --- | --- | | Non-manifold edges | 0 | 0 | | Loose verts / edges | 0 / 0 | 0 / 0 | | Doubles merged at 1e-5 | 0 | 0 | | Zero-area faces | 0 | 0 | | N-gons | 0 | 0 | | Coplanar disjoint face pairs | 0 | 0 | | Grounded: zmin | within 1e-4 of 0 | 0.0000 | | Named supports: 4 wrap feet | each zmin ≤ 1e-3 | 4, foot_z 0.00000 | | Frame plan | 1.36 × 0.92 m ± 0.04 | 1.3600 × 0.9200 |
Joint fit and seat
| Axis | Declared | Measured (all three) | | --- | --- | --- | | Brace-vs-counter overlap | ≤ 1e-6 m³ | 0.000000 | | Header-post tenon engage | ≥ 0.4 × tenon | 0.0595 | | Awning-on-header seat | −0.002–0.010 m | 0.00378 | | Post plumb (XY drift) | ≤ 0.008 m | 0.00000 |
DECIMATE COLLAPSE triangle counts are not identical across series — the gate is a ratio band, not an exact count. Bake pixels are stochastic; the gate is has_data plus operator FINISHED, not byte-identity. Construction uses no RNG. Export byte counts differ by 24 B on 5.2.1 (glTF serializer), not a gated axis.
Falsifiers
Each violates one named budget. All eight were run on 4.5.11, 5.1.2 and 5.2.1 and returned the same code on each.
| Flag | Budget violated | Exit | | --- | --- | --- | | --skip-decimate | LOD1 ratio band | 9 | | --stray-vert | loose vertex count is 0 | 15 | | --lift-z | bounding box zmin is 0 | 16 | | --short-feet | named wrap-foot supports at Z=0 | 16 | | --low-brace | brace-vs-counter overlap | 17 | | --float-awning | awning-on-header seat | 18 | | --rake-posts | post plumb | 19 |
Run
blender --background --python market_stall.py --
blender --background --python market_stall.py -- --skip-decimate
blender --background --python market_stall.py -- --stray-vert
blender --background --python market_stall.py -- --lift-z
blender --background --python market_stall.py -- --short-feet
blender --background --python market_stall.py -- --low-brace
blender --background --python market_stall.py -- --float-awning
blender --background --python market_stall.py -- --rake-posts
blender --background --python market_stall.py -- --output stall.png
Smoke passes no flags.
Exit codes
File-local. 9 is a valid check code. 10 is reserved for gallery_framing.check_framing on the --output path. 15–19 are the hygiene and joint-fit family.
| Code | Meaning | | --- | --- | | 0 | Success | | 1 | Uncaught exception (FATAL wrapper) | | 2 | argparse / usage | | 3 | Mesh did not build / no UV layer | | 4 | Base triangle count outside range | | 5 | Material count ≠ 3 distinct slots, or stripe faces missing | | 6 | UVs outside 0..1 | | 7 | UV AABB overlap above tolerance | | 8 | World AABB off declared outer size | | 9 | LOD ratio band (--skip-decimate lands here) | | 10 | Framing gate (render path only) | | 11 | Collider triangle count above ceiling | | 12 | Bake did not finish or image has no data | | 13 | Export file missing or empty | | 14 | --output produced no file | | 15 | Mesh hygiene: loose, non-manifold, zero-area, doubles, n-gons, z-fight | | 16 | Not grounded: bounding box zmin off 0, or a named wrap foot floats | | 17 | Joint fit: brace occupying the counter volume | | 18 | Seat: awning-on-header gap | | 19 | Post plumb or frame plan off the stated real-world size |
Source
"""Game-ready market stall — a showcase piece, not an example. Asserts budget conformance of a procedural timber stall after composing shipped pipeline pieces: bmesh construction, UVs, three materials, high-to-low normal bake, LOD chain, convex collider, Unity glTF export. Budgets are declared below and recomputed from the generated result. They are not API-contract witnesses. Each falsifier violates one named budget: ``--skip-decimate`` the LOD-ratio band, ``--stray-vert`` mesh hygiene, ``--lift-z`` grounded zmin, ``--short-feet`` named post-foot supports, ``--low-brace`` brace-vs-counter joint fit, ``--float-awning`` awning-on-header seat, ``--rake-posts`` post plumb. No RNG. Slat jitter is closed-form ``sin(i)``. DECIMATE COLLAPSE triangle counts are not byte-identical across Blender versions — the LOD gate is a ratio band, not an exact count. blender --background --python market_stall.py -- blender --background --python market_stall.py -- --skip-decimate blender --background --python market_stall.py -- --output stall.png """ import argparse import math import os import sys import tempfile import traceback import bmesh import bpy from mathutils import Euler, Vector # Showcase lives at repo-root/showcase/, not under examples/. The framing # helper is the repo's only shared import and lives next to the examples; # resolve the repo root so we do not move gallery_framing.py. _REPO = os.path.abspath( os.path.join(os.path.dirname(os.path.abspath(__file__)), os.pardir, os.pardir) ) sys.path.insert(0, os.path.join(_REPO, "examples")) sys.dont_write_bytecode = True import gallery_framing # noqa: E402 WIDTH = 1.36 DEPTH = 0.92 POST = 0.070 FRONT_H = 1.28 BACK_H = 1.72 N_STRIPES = 8 AWNING_T = 0.018 OVERHANG_F = 0.040 OVERHANG_B = 0.030 COUNTER_Z = 0.82 COUNTER_D = 0.34 COUNTER_T = 0.070 BRACE = 0.036 FOOT_H = 0.036 TENON = POST * 0.35 BBOX_TOL = 0.01 # Fitted to the generated AABB after locking geometry. Recomputed from bound_box. OUTER_SIZE = (1.389, 1.011, 1.740) BASE_TRIS_MIN = 3900 BASE_TRIS_MAX = 5200 LOD1_RATIO_MIN = 0.32 LOD1_RATIO_MAX = 0.62 LOD2_RATIO_MIN = 0.10 LOD2_RATIO_MAX = 0.35 LOD1_TARGET = 0.50 LOD2_TARGET = 0.22 MATERIAL_COUNT = 3 UV_EPS = 1e-4 UV_OVERLAP_MAX = 1e-5 COLLIDER_TRIS_MAX = 80 BAKE_RES = 256 CAGE_EXTRUSION = 0.06 ZMIN_EPS = 1e-4 DOUBLES_EPS = 1e-5 AREA_EPS = 1e-10 ZFIGHT_EPS = 1e-4 ZFIGHT_COS = 0.998 FOOT_ZMIN_MAX = 0.001 FOOT_COUNT = 4 AWNING_SEAT_MAX = 0.010 AWNING_SEAT_MIN = -0.002 BRACE_COUNTER_OVERLAP_MAX = 1e-6 POST_PLUMB_MAX = 0.008 FRAME_XY_TOL = 0.04 LIFT_Z = 0.05 # Small enough that the AABB still sits in BBOX_TOL; large enough that # the front-eave seat drops below AWNING_SEAT_MIN. FLOAT_AWNING = 0.008 RAKE = math.radians(2.0) SHORT_FOOT_Z = 0.048 WOOD_IDX = 0 STRIPE_A_IDX = 1 STRIPE_B_IDX = 2 def eevee_engine_id(): return "BLENDER_EEVEE" if bpy.app.version >= (5, 0, 0) else "BLENDER_EEVEE_NEXT" def fail(msg, code): print(f"ERROR: {msg}", file=sys.stderr) return code def triangle_count(mesh): mesh.calc_loop_triangles() return len(mesh.loop_triangles) def evaluated_triangle_count(obj): # Duplicated from snippets/lod_chain.py / decimate_to_budget.py (not a package). depsgraph = bpy.context.evaluated_depsgraph_get() eval_obj = obj.evaluated_get(depsgraph) eval_mesh = eval_obj.to_mesh() try: eval_mesh.calc_loop_triangles() return len(eval_mesh.loop_triangles) finally: eval_obj.to_mesh_clear() def add_box(bm, loc, scale, mat_idx, euler=(0.0, 0.0, 0.0)): geo = bmesh.ops.create_cube(bm, size=1.0) verts = geo["verts"] rot = Euler(euler).to_matrix() origin = Vector(loc) for v in verts: p = Vector((v.co.x * scale[0], v.co.y * scale[1], v.co.z * scale[2])) v.co = rot @ p + origin faces = {f for v in verts for f in v.link_faces} for f in faces: f.material_index = mat_idx return verts def add_oriented_box(bm, a, b, scale_xy, mat_idx): a = Vector(a) b = Vector(b) delta = b - a length = delta.length if length < 1e-8: return [] quat = Vector((0.0, 0.0, 1.0)).rotation_difference(delta.normalized()) eul = quat.to_euler("XYZ") return add_box( bm, ((a + b) * 0.5), (scale_xy[0], scale_xy[1], length), mat_idx, euler=(eul.x, eul.y, eul.z), ) def add_wrap(bm, px, py, z, height, host, t, mat_idx): """Four plates around a square post. Y-facing plates cover the corners.""" half = host / 2.0 off = half + t / 2.0 + 0.002 add_box(bm, (px + off, py, z), (t, host, height), mat_idx) add_box(bm, (px - off, py, z), (t, host, height), mat_idx) add_box(bm, (px, py + off, z), (host + 2.0 * t, t, height), mat_idx) add_box(bm, (px, py - off, z), (host + 2.0 * t, t, height), mat_idx) return [] def add_striped_slab(bm, loc, scale, euler, n_stripes, even_idx, odd_idx): """One slab split into n stripes that share vertices — no daylight gaps.""" rot = Euler(euler).to_matrix() origin = Vector(loc) sx, sy, sz = scale stations = [] for i in range(n_stripes + 1): x = -0.5 * sx + sx * i / n_stripes row = [] for y, z in ( (-0.5 * sy, -0.5 * sz), (-0.5 * sy, 0.5 * sz), (0.5 * sy, -0.5 * sz), (0.5 * sy, 0.5 * sz), ): row.append(bm.verts.new(rot @ Vector((x, y, z)) + origin)) stations.append(row) kept = [] for i in range(n_stripes): a = stations[i] b = stations[i + 1] idx = even_idx if (i % 2 == 0) else odd_idx quads = ( (a[0], b[0], b[2], a[2]), (a[1], a[3], b[3], b[1]), (a[0], a[1], b[1], b[0]), (a[2], b[2], b[3], a[3]), ) for q in quads: face = bm.faces.new(q) face.material_index = idx kept.append(face) first = stations[0] last = stations[-1] cap_a = bm.faces.new((first[0], first[2], first[3], first[1])) cap_a.material_index = even_idx cap_b = bm.faces.new((last[0], last[1], last[3], last[2])) cap_b.material_index = even_idx if ((n_stripes - 1) % 2 == 0) else odd_idx kept.extend((cap_a, cap_b)) return kept def pack_uvs(bm, margin=0.08): uv = bm.loops.layers.uv.new("UVMap") faces = list(bm.faces) n = len(faces) cols = max(1, math.ceil(math.sqrt(n))) rows = max(1, math.ceil(n / cols)) cell_w = 1.0 / cols cell_h = 1.0 / rows pad_u = margin * cell_w * 0.5 pad_v = margin * cell_h * 0.5 usable_w = cell_w - 2.0 * pad_u usable_h = cell_h - 2.0 * pad_v for i, face in enumerate(faces): col = i % cols row = i // cols nrm = face.normal ax = abs(nrm.x) ay = abs(nrm.y) az = abs(nrm.z) coords = [] for loop in face.loops: co = loop.vert.co if az >= ax and az >= ay: coords.append((co.x, co.y)) elif ax >= ay: coords.append((co.y, co.z)) else: coords.append((co.x, co.z)) xs = [c[0] for c in coords] ys = [c[1] for c in coords] minx, maxx = min(xs), max(xs) miny, maxy = min(ys), max(ys) dx = max(maxx - minx, 1e-8) dy = max(maxy - miny, 1e-8) origin_u = col * cell_w + pad_u origin_v = row * cell_h + pad_v for loop, (x, y) in zip(face.loops, coords): loop[uv].uv = ( origin_u + (x - minx) / dx * usable_w, origin_v + (y - miny) / dy * usable_h, ) def build_stall_mesh( name, bevel_offset, bevel_segments, low_brace=False, float_awning=False, rake_posts=False, short_feet=False, ): bm = bmesh.new() wood_verts = [] stripe_faces = [] try: hx = WIDTH / 2.0 hy = DEPTH / 2.0 px = hx - POST / 2.0 py_f = -(hy - POST / 2.0) py_b = hy - POST / 2.0 post_h_f = FRONT_H - POST post_h_b = BACK_H - POST rake = (RAKE, 0.0, 0.0) if rake_posts else (0.0, 0.0, 0.0) posts = ( (-px, py_f, post_h_f), (px, py_f, post_h_f), (-px, py_b, post_h_b), (px, py_b, post_h_b), ) foot_z = SHORT_FOOT_Z if short_feet else FOOT_H / 2.0 foot_h = 0.020 if short_feet else FOOT_H wrap_t = POST * 0.18 for x, y, h in posts: wood_verts.extend( add_box(bm, (x, y, h / 2.0), (POST, POST, h), WOOD_IDX, euler=rake) ) add_wrap(bm, x, y, foot_z, foot_h, POST, wrap_t, WOOD_IDX) header_len = WIDTH - POST + 2.0 * TENON wood_verts.extend( add_box( bm, (0.0, py_f, FRONT_H - POST / 2.0), (header_len, POST * 0.78, POST), WOOD_IDX, ) ) wood_verts.extend( add_box( bm, (0.0, py_b, BACK_H - POST / 2.0), (header_len, POST * 0.78, POST), WOOD_IDX, ) ) # Side plates sit on the header centres, spanning post to post. for sx in (-px, px): wood_verts.extend( add_oriented_box( bm, (sx, py_f, FRONT_H - POST / 2.0), (sx, py_b, BACK_H - POST / 2.0), (POST * 0.80, POST * 0.80), WOOD_IDX, ) ) for i in range(3): rx = -hx + POST * 2.0 + (i + 1) * (WIDTH - 4.0 * POST) / 4.0 wood_verts.extend( add_oriented_box( bm, (rx, py_f, FRONT_H - POST / 2.0), (rx, py_b, BACK_H - POST / 2.0), (POST * 0.42, POST * 0.42), WOOD_IDX, ) ) wood_verts.extend( add_box( bm, (0.0, py_b, BACK_H * 0.48), (WIDTH - POST, POST * 0.65, POST * 0.65), WOOD_IDX, ) ) wood_verts.extend( add_box( bm, (0.0, py_f, 0.16), (WIDTH - 2.0 * POST, POST * 0.70, POST * 0.55), WOOD_IDX, ) ) for sign in (-1.0, 1.0): sx = sign * px if low_brace: a = Vector((sx, py_f, 0.28)) b = Vector((sx, py_b, BACK_H * 0.58)) else: # On the post centreline so the brace tenons the post instead # of reading as a wing in the front elevation. a = Vector((sx, 0.04, COUNTER_Z + 0.14)) b = Vector((sx, py_b, BACK_H * 0.56)) wood_verts.extend(add_oriented_box(bm, a, b, (BRACE, BRACE), WOOD_IDX)) inner_w = WIDTH - 2.0 * POST - 0.024 y0 = py_f + POST / 2.0 + 0.016 y1 = y0 + COUNTER_D n_slats = 6 slat_gap = 0.008 slat_d = (COUNTER_D - (n_slats - 1) * slat_gap) / n_slats for i in range(n_slats): jw = 0.018 * math.sin(i * 2.31 + 0.5) jt = 0.006 * math.sin(i * 1.87) y = y0 + slat_d / 2.0 + i * (slat_d + slat_gap) wood_verts.extend( add_box( bm, (0.0, y, COUNTER_Z), (inner_w + jw, slat_d * 0.94, COUNTER_T * 0.62 + jt), WOOD_IDX, ) ) wood_verts.extend( add_box( bm, (0.0, y0 + 0.016, COUNTER_Z - 0.08), (inner_w * 0.96, 0.032, 0.14), WOOD_IDX, ) ) shelf_z = 0.38 n_shelf = 4 shelf_d = COUNTER_D * 0.78 shelf_gap = 0.008 shelf_slat = (shelf_d - (n_shelf - 1) * shelf_gap) / n_shelf sy0 = y0 + 0.04 + shelf_slat / 2.0 for i in range(n_shelf): jw = 0.014 * math.sin(i * 1.63 + 0.9) wood_verts.extend( add_box( bm, (0.0, sy0 + i * (shelf_slat + shelf_gap), shelf_z), (inner_w - 0.08 + jw, shelf_slat * 0.94, 0.024), WOOD_IDX, ) ) leg_h = COUNTER_Z - COUNTER_T * 0.32 for lx in (-inner_w / 2.0 + 0.04, inner_w / 2.0 - 0.04): for ly in (y0 + 0.05, y1 - 0.05): wood_verts.extend( add_box(bm, (lx, ly, leg_h / 2.0), (0.042, 0.042, leg_h), WOOD_IDX) ) plank_y = py_b - POST / 2.0 - 0.014 plank_len = WIDTH - POST for i in range(5): z = 0.30 + i * 0.148 jw = 0.004 * math.sin(i * 2.11) wood_verts.extend( add_box( bm, (0.0, plank_y, z), (plank_len + jw, 0.028, 0.118), WOOD_IDX, ) ) fascia_y = -hy - OVERHANG_F wood_verts.extend( add_box( bm, (0.0, fascia_y, FRONT_H - 0.022), (WIDTH - POST * 0.2, 0.032, 0.044), WOOD_IDX, ) ) wood_verts.extend( add_box( bm, (0.0, fascia_y - 0.006, FRONT_H - 0.004), (WIDTH - POST * 0.05, 0.022, 0.022), WOOD_IDX, ) ) # Centreline sits above the header; thickness then hangs along the # roof normal so the front underside clears the fascia top. seat = 0.012 front = Vector((0.0, -hy - OVERHANG_F, FRONT_H + seat)) back = Vector((0.0, hy + OVERHANG_B, BACK_H + seat)) dy = back.y - front.y dz = back.z - front.z awning_len = math.hypot(dy, dz) pitch = math.atan2(dz, dy) nrm = Vector((0.0, -math.sin(pitch), math.cos(pitch))) mid = (front + back) * 0.5 if float_awning: mid = Vector((mid.x, mid.y, mid.z + FLOAT_AWNING)) stripe_faces.extend( add_striped_slab( bm, mid, (WIDTH, awning_len, AWNING_T), (pitch, 0.0, 0.0), N_STRIPES, STRIPE_A_IDX, STRIPE_B_IDX, ) ) val_z = FRONT_H - 0.09 + (FLOAT_AWNING if float_awning else 0.0) stripe_faces.extend( add_striped_slab( bm, (0.0, fascia_y - 0.002, val_z), (WIDTH, 0.014, 0.15), (0.0, 0.0, 0.0), N_STRIPES, STRIPE_B_IDX, STRIPE_A_IDX, ) ) if bevel_offset > 0.0: edges = list({e for v in wood_verts for e in v.link_edges}) bmesh.ops.bevel( bm, geom=edges, offset=bevel_offset, segments=bevel_segments, profile=0.5, affect="EDGES", clamp_overlap=True, ) zmin = min(v.co.z for v in bm.verts) for v in bm.verts: v.co.z -= zmin if v.co.z < 0.002: v.co.z = 0.0 pack_uvs(bm) bmesh.ops.recalc_face_normals(bm, faces=list(bm.faces)) for face in bm.faces: face.smooth = False for edge in bm.edges: edge.smooth = False if edge.is_manifold and len(edge.link_faces) == 2: if edge.calc_face_angle() < math.radians(25.0): edge.smooth = True for face in stripe_faces: if face.is_valid: pass me = bpy.data.meshes.new(name) bm.to_mesh(me) me.update() finally: bm.free() obj = bpy.data.objects.new(name, me) bpy.context.collection.objects.link(obj) return obj def principled(name, color, metallic, roughness): mat = bpy.data.materials.new(name) mat.use_nodes = True bsdf = mat.node_tree.nodes["Principled BSDF"] bsdf.inputs["Base Color"].default_value = color bsdf.inputs["Metallic"].default_value = metallic bsdf.inputs["Roughness"].default_value = roughness return mat def assign_slots(obj, wood, stripe_a, stripe_b): # Do not materials.clear() — that resets polygon material_index to 0 # on this Blender, which would drop awning stripes onto wood. mats = obj.data.materials wanted = (wood, stripe_a, stripe_b) for i, mat in enumerate(wanted): if i < len(mats): mats[i] = mat else: mats.append(mat) def world_bbox(obj): corners = [obj.matrix_world @ Vector(c) for c in obj.bound_box] xs = [c.x for c in corners] ys = [c.y for c in corners] zs = [c.z for c in corners] return (min(xs), min(ys), min(zs), max(xs), max(ys), max(zs)) def uv_stats(mesh): uv = mesh.uv_layers.active if uv is None: return 0.0, 0.0, 1.0, 1.0, 0, 1.0 data = uv.data us = [loop.uv[0] for loop in data] vs = [loop.uv[1] for loop in data] aabbs = [] for poly in mesh.polygons: pu = [data[i].uv[0] for i in poly.loop_indices] pv = [data[i].uv[1] for i in poly.loop_indices] aabbs.append((min(pu), min(pv), max(pu), max(pv))) overlap = 0.0 for i in range(len(aabbs)): a = aabbs[i] for j in range(i + 1, len(aabbs)): b = aabbs[j] x0 = max(a[0], b[0]) y0 = max(a[1], b[1]) x1 = min(a[2], b[2]) y1 = min(a[3], b[3]) overlap += max(0.0, x1 - x0) * max(0.0, y1 - y0) return min(us), min(vs), max(us), max(vs), overlap, len(aabbs) def face_area(me, poly): vs = [me.vertices[i].co for i in poly.vertices] if len(vs) < 3: return 0.0 v0 = vs[0] area = 0.0 for i in range(1, len(vs) - 1): area += (vs[i] - v0).cross(vs[i + 1] - v0).length * 0.5 return area def hygiene_audit(me): # Combinatorics match examples/mesh-hygiene-audit.audit (copied, not imported). nv, ne, nf = len(me.vertices), len(me.edges), len(me.polygons) ngons = sum(1 for p in me.polygons if len(p.vertices) > 4) zero_area = sum(1 for p in me.polygons if face_area(me, p) <= AREA_EPS) bm = bmesh.new() try: bm.from_mesh(me) bm.verts.ensure_lookup_table() bm.edges.ensure_lookup_table() loose_v = sum(1 for v in bm.verts if len(v.link_edges) == 0) loose_e = sum(1 for e in bm.edges if len(e.link_faces) == 0) nonman = sum(1 for e in bm.edges if not e.is_manifold) ret = bmesh.ops.find_doubles(bm, verts=list(bm.verts), dist=DOUBLES_EPS) doubles = len(ret.get("targetmap") or {}) finally: bm.free() return { "nv": nv, "ne": ne, "nf": nf, "ngons": ngons, "loose_v": loose_v, "loose_e": loose_e, "nonman": nonman, "zero_area": zero_area, "doubles": doubles, "euler": nv - ne + nf, } def zfight_pairs(me): data = [ (p.center.copy(), p.normal.copy(), frozenset(p.vertices)) for p in me.polygons ] eps2 = ZFIGHT_EPS * ZFIGHT_EPS count = 0 for i in range(len(data)): ci, ni, vi = data[i] for j in range(i + 1, len(data)): cj, nj, vj = data[j] if (cj - ci).length_squared > eps2: continue if abs(ni.dot(nj)) <= ZFIGHT_COS: continue if vi & vj: continue count += 1 return count def shells(me): neighbors = [[] for _ in range(len(me.vertices))] for edge in me.edges: a, b = edge.vertices neighbors[a].append(b) neighbors[b].append(a) seen = [False] * len(me.vertices) groups = [] for start in range(len(me.vertices)): if seen[start]: continue seen[start] = True stack = [start] group = [] while stack: current = stack.pop() group.append(current) for nxt in neighbors[current]: if not seen[nxt]: seen[nxt] = True stack.append(nxt) groups.append(group) return groups def shell_aabb(me, group): pts = [me.vertices[i].co for i in group] return ( min(p.x for p in pts), min(p.y for p in pts), min(p.z for p in pts), max(p.x for p in pts), max(p.y for p in pts), max(p.z for p in pts), ) def aabb_overlap(a, b): x = min(a[3], b[3]) - max(a[0], b[0]) y = min(a[4], b[4]) - max(a[1], b[1]) z = min(a[5], b[5]) - max(a[2], b[2]) if x <= 0.0 or y <= 0.0 or z <= 0.0: return 0.0 return x * y * z def mat_of(me, group): member = set(group) for poly in me.polygons: if all(i in member for i in poly.vertices): return poly.material_index return None def support_audit(me): """Post feet: wrap plates clustered at the four frame corners.""" plates = [] for group in shells(me): if mat_of(me, group) != WOOD_IDX: continue a = shell_aabb(me, group) dz = a[5] - a[2] dx = a[3] - a[0] dy = a[4] - a[1] cz = 0.5 * (a[2] + a[5]) if cz > 0.10 or dz > 0.10: continue if max(dx, dy) < POST * 0.8: continue plates.append(a) corners = {} for a in plates: cx = 0.5 * (a[0] + a[3]) cy = 0.5 * (a[1] + a[4]) key = (1 if cx > 0.0 else -1, 1 if cy > 0.0 else -1) corners.setdefault(key, []).append(a) zmin = min((a[2] for a in plates), default=99.0) return {"feet": len(corners), "foot_z": zmin} def joint_audit(me): """Braces must not occupy the counter volume. Headers bite the posts.""" hx = WIDTH / 2.0 groups = shells(me) boxes = [(g, shell_aabb(me, g), mat_of(me, g)) for g in groups] posts = [] headers = [] braces = [] slats = [] for _g, a, mat in boxes: if mat != WOOD_IDX: continue dx, dy, dz = a[3] - a[0], a[4] - a[1], a[5] - a[2] cx = 0.5 * (a[0] + a[3]) cy = 0.5 * (a[1] + a[4]) cz = 0.5 * (a[2] + a[5]) if dz > FRONT_H * 0.55 and dx < POST * 2.4 and dy < POST * 2.4: posts.append(a) continue if dx > WIDTH * 0.6 and dz < POST * 2.2 and dy < POST * 2.2 and cz > FRONT_H * 0.7: headers.append(a) continue if abs(cx) > hx - POST * 1.8 and dz > 0.35 and dy > 0.25 and dx < 0.20: braces.append(a) continue if abs(cz - COUNTER_Z) < 0.08 and dx > WIDTH * 0.4: slats.append(a) overlap = 0.0 for brace in braces: for slat in slats: overlap = max(overlap, aabb_overlap(brace, slat)) pairs = [ min(h[3] - p[0], p[3] - h[0]) for h in headers for p in posts if abs(0.5 * (h[1] + h[4]) - 0.5 * (p[1] + p[4])) < POST * 2.0 ] engage = min(pairs) if pairs else 1.0 return { "posts": len(posts), "headers": len(headers), "braces": len(braces), "slats": len(slats), "overlap": overlap, "engage": engage, } def awning_seat(me): """Gap from front-header top to awning underside, at the front eave.""" hy = DEPTH / 2.0 wood_z = [] stripe_z = [] for poly in me.polygons: zs = [me.vertices[i].co.z for i in poly.vertices] ys = [me.vertices[i].co.y for i in poly.vertices] cy = sum(ys) / len(ys) if cy > -hy + 0.15: continue zmax = max(zs) zmin = min(zs) if poly.material_index == WOOD_IDX and zmax > FRONT_H - 0.12: if max(ys) - min(ys) > 0.028: wood_z.append(zmax) if poly.material_index in (STRIPE_A_IDX, STRIPE_B_IDX) and zmax > FRONT_H: stripe_z.append(zmin) if not wood_z or not stripe_z: return 99.0 return min(stripe_z) - max(wood_z) def plumb_audit(me): """XY centroid of each post's bottom slab vs top slab.""" drifts = [] for group in shells(me): if mat_of(me, group) != WOOD_IDX: continue a = shell_aabb(me, group) dz = a[5] - a[2] dx = a[3] - a[0] dy = a[4] - a[1] if dz < FRONT_H * 0.55 or dx > POST * 2.4 or dy > POST * 2.4: continue pts = [me.vertices[i].co for i in group] zcut_lo = a[2] + 0.08 * dz zcut_hi = a[5] - 0.08 * dz lo = [p for p in pts if p.z <= zcut_lo] hi = [p for p in pts if p.z >= zcut_hi] if len(lo) < 3 or len(hi) < 3: continue c_lo = Vector((sum(p.x for p in lo) / len(lo), sum(p.y for p in lo) / len(lo))) c_hi = Vector((sum(p.x for p in hi) / len(hi), sum(p.y for p in hi) / len(hi))) drifts.append((c_hi - c_lo).length) return max(drifts) if drifts else 99.0 def frame_size(me): """Post-foot envelope vs declared stall plan, not the awning AABB.""" hx = WIDTH / 2.0 hy = DEPTH / 2.0 xs, ys, zs = [], [], [] for group in shells(me): if mat_of(me, group) != WOOD_IDX: continue a = shell_aabb(me, group) dz = a[5] - a[2] dx = a[3] - a[0] dy = a[4] - a[1] cx = 0.5 * (a[0] + a[3]) cy = 0.5 * (a[1] + a[4]) if dz > FRONT_H * 0.55 and dx < POST * 2.4 and dy < POST * 2.4: xs.extend((a[0], a[3])) ys.extend((a[1], a[4])) zs.append(a[5]) continue if dz < 0.08 and abs(cx) > hx - POST * 1.6 and abs(cy) > hy - POST * 1.6: zs.append(a[2]) if not xs: return 0.0, 0.0, 0.0 return max(xs) - min(xs), max(ys) - min(ys), max(zs) - min(zs) def add_stray_vert(me): bm = bmesh.new() try: bm.from_mesh(me) bm.verts.new((0.0, 0.0, COUNTER_Z)) bm.to_mesh(me) me.update() finally: bm.free() def make_lod(obj, name, ratio, skip_decimate): mesh = obj.data.copy() lod = bpy.data.objects.new(name, mesh) lod.matrix_world = obj.matrix_world.copy() bpy.context.scene.collection.objects.link(lod) if not skip_decimate and 0.0 < ratio < 1.0: mod = lod.modifiers.new("DecimateBudget", "DECIMATE") mod.decimate_type = "COLLAPSE" mod.ratio = ratio return lod def convex_hull_collider(obj, name): # Duplicated from snippets/convex_hull_collider.py (not a package). mesh = bpy.data.meshes.new(name) bm = bmesh.new() try: bm.from_mesh(obj.data) result = bmesh.ops.convex_hull(bm, input=list(bm.verts)) interior = result.get("geom_interior") or [] unused = result.get("geom_unused") or [] if interior: bmesh.ops.delete(bm, geom=interior, context="VERTS") if unused: bmesh.ops.delete(bm, geom=unused, context="VERTS") bm.to_mesh(mesh) mesh.update() finally: bm.free() collider = bpy.data.objects.new(name, mesh) bpy.context.collection.objects.link(collider) collider.matrix_world = obj.matrix_world.copy() return collider def setup_bake_image(obj, target_mat, size=BAKE_RES): # Adapted from snippets/setup_bake_target_image.py — do not replace slots. if not obj.data.uv_layers: return None, None img = bpy.data.images.new("StallNrm", size, size, alpha=True, float_buffer=False) img.colorspace_settings.name = "Non-Color" nodes = target_mat.node_tree.nodes tex = nodes.new("ShaderNodeTexImage") tex.image = img nodes.active = tex tex.select = True obj.active_material_index = WOOD_IDX return img, tex def bake_normal(high, low): # Duplicated from snippets/bake_normal_high_to_low.py (not a package). scene = bpy.context.scene scene.render.engine = "CYCLES" scene.cycles.device = "CPU" scene.cycles.samples = 1 scene.cycles.use_denoising = False for ob in bpy.context.view_layer.objects: ob.select_set(False) high.select_set(True) low.select_set(True) bpy.context.view_layer.objects.active = low return bpy.ops.object.bake( type="NORMAL", use_selected_to_active=True, cage_extrusion=CAGE_EXTRUSION, use_cage=False, normal_space="TANGENT", margin=4, margin_type="ADJACENT_FACES", use_clear=True, target="IMAGE_TEXTURES", ) def export_unity(path, objects): # Duplicated from snippets/export_preset_unity.py (not a package). for ob in bpy.context.view_layer.objects: ob.select_set(False) for ob in objects: ob.select_set(True) bpy.context.view_layer.objects.active = objects[0] bpy.ops.export_scene.gltf( filepath=path, use_selection=True, export_yup=True, export_apply=True, export_draco_mesh_compression_enable=False, export_animations=False, ) def check( skip_decimate, lift_z=False, stray_vert=False, short_feet=False, low_brace=False, float_awning=False, rake_posts=False, ): bpy.ops.wm.read_factory_settings(use_empty=True) low = build_stall_mesh( "StallLow", bevel_offset=0.006, bevel_segments=2, low_brace=low_brace, float_awning=float_awning, rake_posts=rake_posts, short_feet=short_feet, ) high = build_stall_mesh( "StallHigh", bevel_offset=0.006, bevel_segments=4, low_brace=low_brace, float_awning=float_awning, rake_posts=rake_posts, short_feet=short_feet, ) wood = principled("StallWood", (0.42, 0.24, 0.10, 1.0), 0.0, 0.55) stripe_a = principled("StallStripeA", (0.72, 0.12, 0.10, 1.0), 0.0, 0.62) stripe_b = principled("StallStripeB", (0.86, 0.80, 0.62, 1.0), 0.0, 0.58) assign_slots(low, wood, stripe_a, stripe_b) assign_slots(high, wood, stripe_a, stripe_b) if stray_vert: add_stray_vert(low.data) if lift_z: for v in low.data.vertices: v.co.z += LIFT_Z low.data.update() if low.data is None or len(low.data.polygons) < 6: return fail("stall mesh did not build", 3), None, None, None, None, None base_tris = triangle_count(low.data) mats = [s for s in low.data.materials if s is not None] nmat = len(mats) distinct_mats = len({id(s) for s in mats}) idx_counts = {} for poly in low.data.polygons: idx_counts[poly.material_index] = idx_counts.get(poly.material_index, 0) + 1 print(f"measured mat_index_counts={idx_counts}") u0, v0, u1, v1, overlap, nfaces = uv_stats(low.data) bb = world_bbox(low) size_x = bb[3] - bb[0] size_y = bb[4] - bb[1] size_z = bb[5] - bb[2] hyg = hygiene_audit(low.data) zf = zfight_pairs(low.data) sup = support_audit(low.data) jnt = joint_audit(low.data) seat = awning_seat(low.data) plumb = plumb_audit(low.data) fx, fy, fz = frame_size(low.data) img, tex = setup_bake_image(low, wood) if img is None: return fail("stall has no UV layer", 3), None, None, None, None, None bake_result = bake_normal(high, low) lod1 = make_lod(low, "StallLOD1", LOD1_TARGET, skip_decimate) lod2 = make_lod(low, "StallLOD2", LOD2_TARGET, skip_decimate) bpy.context.view_layer.update() lod1_tris = evaluated_triangle_count(lod1) lod2_tris = evaluated_triangle_count(lod2) r1 = lod1_tris / base_tris if base_tris else 0.0 r2 = lod2_tris / base_tris if base_tris else 0.0 collider_src = build_stall_mesh("StallColSrc", bevel_offset=0.0, bevel_segments=1) collider = convex_hull_collider(collider_src, "StallCollider") bpy.data.objects.remove(collider_src, do_unlink=True) col_tris = triangle_count(collider.data) export_path = os.path.join( tempfile.gettempdir(), f"bdt_market_stall_{os.getpid()}.glb", ) if os.path.exists(export_path): os.remove(export_path) export_unity(export_path, [low, collider]) export_size = os.path.getsize(export_path) if os.path.isfile(export_path) else 0 print(f"blender={tuple(bpy.app.version)} skip_decimate={skip_decimate}") print( f"measured base_tris={base_tris} lod1_tris={lod1_tris} " f"lod2_tris={lod2_tris} r1={r1:.4f} r2={r2:.4f}" ) print( f"measured nmat={nmat} uv=({u0:.4f},{v0:.4f})-({u1:.4f},{v1:.4f}) " f"overlap={overlap:.6f} nfaces={nfaces}" ) print( f"measured bbox=({size_x:.4f},{size_y:.4f},{size_z:.4f}) " f"outer={OUTER_SIZE} zmin={bb[2]:.4f}" ) print( f"measured collider_tris={col_tris} bake={bake_result} " f"bake_has_data={img.has_data} export_bytes={export_size}" ) print( f"measured hygiene loose_v={hyg['loose_v']} loose_e={hyg['loose_e']} " f"nonman={hyg['nonman']} zero_area={hyg['zero_area']} " f"doubles={hyg['doubles']} ngons={hyg['ngons']} zfight={zf}" ) print( f"measured feet={sup['feet']} foot_z={sup['foot_z']:.5f} " f"brace_overlap={jnt['overlap']:.6f} engage={jnt['engage']:.4f} " f"seat={seat:.5f} plumb={plumb:.5f} frame=({fx:.4f},{fy:.4f},{fz:.4f})" ) if not (BASE_TRIS_MIN <= base_tris <= BASE_TRIS_MAX): return fail( f"base tris {base_tris} not in [{BASE_TRIS_MIN}, {BASE_TRIS_MAX}]", 4, ), None, None, None, None, None if nmat != MATERIAL_COUNT or distinct_mats != MATERIAL_COUNT: return fail( f"material slots {nmat} distinct {distinct_mats} != {MATERIAL_COUNT}", 5, ), None, None, None, None, None if idx_counts.get(STRIPE_A_IDX, 0) < 16: return fail( f"stripe A faces {idx_counts.get(STRIPE_A_IDX, 0)} < 16", 5, ), None, None, None, None, None if idx_counts.get(STRIPE_B_IDX, 0) < 16: return fail( f"stripe B faces {idx_counts.get(STRIPE_B_IDX, 0)} < 16", 5, ), None, None, None, None, None if u0 < -UV_EPS or v0 < -UV_EPS or u1 > 1.0 + UV_EPS or v1 > 1.0 + UV_EPS: return fail( f"UVs outside 0..1: ({u0:.4f},{v0:.4f})-({u1:.4f},{v1:.4f})", 6, ), None, None, None, None, None if overlap > UV_OVERLAP_MAX: return fail( f"UV AABB overlap {overlap:.6f} > {UV_OVERLAP_MAX}", 7, ), None, None, None, None, None if ( abs(size_x - OUTER_SIZE[0]) > BBOX_TOL or abs(size_y - OUTER_SIZE[1]) > BBOX_TOL or abs(size_z - OUTER_SIZE[2]) > BBOX_TOL ): return fail( f"bbox ({size_x:.4f},{size_y:.4f},{size_z:.4f}) " f"off outer {OUTER_SIZE}", 8, ), None, None, None, None, None if not (LOD1_RATIO_MIN <= r1 <= LOD1_RATIO_MAX): return fail( f"LOD1 ratio {r1:.4f} not in [{LOD1_RATIO_MIN}, {LOD1_RATIO_MAX}] " "(--skip-decimate is the designed fail)", 9, ), None, None, None, None, None if not (LOD2_RATIO_MIN <= r2 <= LOD2_RATIO_MAX): return fail( f"LOD2 ratio {r2:.4f} not in [{LOD2_RATIO_MIN}, {LOD2_RATIO_MAX}]", 9, ), None, None, None, None, None if col_tris > COLLIDER_TRIS_MAX: return fail( f"collider tris {col_tris} > {COLLIDER_TRIS_MAX}", 11, ), None, None, None, None, None if bake_result != {"FINISHED"} or not img.has_data: return fail( f"bake failed result={bake_result} has_data={img.has_data}", 12, ), None, None, None, None, None if export_size <= 0: return fail("export file missing or empty", 13), None, None, None, None, None if ( hyg["loose_v"] or hyg["loose_e"] or hyg["nonman"] or hyg["zero_area"] or hyg["doubles"] or hyg["ngons"] or zf ): return fail( f"hygiene loose_v={hyg['loose_v']} loose_e={hyg['loose_e']} " f"nonman={hyg['nonman']} zero_area={hyg['zero_area']} " f"doubles={hyg['doubles']} ngons={hyg['ngons']} zfight={zf}", 15, ), None, None, None, None, None if bb[2] > ZMIN_EPS or sup["feet"] != FOOT_COUNT or sup["foot_z"] > FOOT_ZMIN_MAX: return fail( f"grounded zmin={bb[2]:.5f} feet={sup['feet']} " f"foot_z={sup['foot_z']:.5f}", 16, ), None, None, None, None, None if jnt["overlap"] > BRACE_COUNTER_OVERLAP_MAX or jnt["engage"] < TENON * 0.4: return fail( f"joint overlap={jnt['overlap']:.6f} engage={jnt['engage']:.4f} " f"posts={jnt['posts']} braces={jnt['braces']} slats={jnt['slats']}", 17, ), None, None, None, None, None if seat < AWNING_SEAT_MIN or seat > AWNING_SEAT_MAX: return fail(f"awning seat gap {seat:.5f} > {AWNING_SEAT_MAX}", 18), None, None, None, None, None if ( plumb > POST_PLUMB_MAX or abs(fx - WIDTH) > FRAME_XY_TOL or abs(fy - DEPTH) > FRAME_XY_TOL ): return fail( f"plumb={plumb:.5f} frame=({fx:.4f},{fy:.4f},{fz:.4f}) " f"off {WIDTH}x{DEPTH}", 19, ), None, None, None, None, None return 0, low, high, wood, tex, collider def wire_normal(mat, tex): nt = mat.node_tree bsdf = nt.nodes["Principled BSDF"] nrm = nt.nodes.new("ShaderNodeNormalMap") nrm.inputs["Strength"].default_value = 1.0 nt.links.new(tex.outputs["Color"], nrm.inputs["Color"]) nt.links.new(nrm.outputs["Normal"], bsdf.inputs["Normal"]) def render_still(low, wood, tex, path, engine): scene = bpy.context.scene wire_normal(wood, tex) for ob in list(scene.objects): if ob.type == "MESH" and ob != low: ob.hide_render = True ob.hide_viewport = True low.rotation_euler.z = math.radians(-18.0) low.rotation_euler.x = math.radians(2.0) floor_me = bpy.data.meshes.new("Floor") bm = bmesh.new() try: bmesh.ops.create_grid(bm, x_segments=1, y_segments=1, size=14.0) bm.to_mesh(floor_me) finally: bm.free() fmat = bpy.data.materials.new("Floor") fmat.use_nodes = True fb = fmat.node_tree.nodes["Principled BSDF"] fb.inputs["Base Color"].default_value = (0.03, 0.032, 0.037, 1.0) fb.inputs["Roughness"].default_value = 0.7 floor_me.materials.append(fmat) floor = bpy.data.objects.new("Floor", floor_me) scene.collection.objects.link(floor) wall = bpy.data.objects.new("Wall", floor_me.copy()) wall.location = (0.0, 8.5, 0.0) wall.rotation_euler = (math.radians(90), 0.0, 0.0) scene.collection.objects.link(wall) world = bpy.data.worlds.new("World") world.use_nodes = True world.node_tree.nodes["Background"].inputs["Color"].default_value = ( 0.02, 0.021, 0.025, 1.0, ) scene.world = world def light(name, loc, energy, size, col, rot): ld = bpy.data.lights.new(name, "AREA") ld.energy = energy ld.size = size ld.color = col ob = bpy.data.objects.new(name, ld) ob.location = loc ob.rotation_euler = tuple(math.radians(a) for a in rot) scene.collection.objects.link(ob) light("Key", (-3.6, -5.0, 5.8), 680.0, 4.0, (1.0, 0.94, 0.86), (50, 0, -36)) light("Fill", (5.0, -3.6, 2.6), 48.0, 8.0, (0.72, 0.82, 1.0), (62, 0, 50)) light("Wedge", (2.4, 4.2, 4.1), 640.0, 5.5, (1.0, 0.70, 0.40), (-70, 0, 198)) bb = world_bbox(low) span = max(bb[3] - bb[0], bb[4] - bb[1], bb[5] - bb[2], 0.2) cam_data = bpy.data.cameras.new("Cam") cam_data.lens = 50.0 cam = bpy.data.objects.new("Cam", cam_data) cam.location = (span * 2.17, -span * 2.95, span * 1.12) scene.collection.objects.link(cam) aim = bpy.data.objects.new("Aim", None) aim.location = (0.0, -0.04 * span, 0.52 * (bb[2] + bb[5])) scene.collection.objects.link(aim) con = cam.constraints.new("TRACK_TO") con.target = aim con.track_axis = "TRACK_NEGATIVE_Z" con.up_axis = "UP_Y" scene.camera = cam scene.render.engine = "CYCLES" if engine == "cycles" else eevee_engine_id() if engine == "cycles": scene.cycles.samples = 32 scene.cycles.device = "CPU" else: try: scene.eevee.taa_render_samples = 64 except AttributeError: pass scene.render.resolution_x = 1280 scene.render.resolution_y = 720 scene.render.image_settings.file_format = ( "WEBP" if path.lower().endswith(".webp") else "PNG" ) if path.lower().endswith(".webp"): scene.render.image_settings.quality = 90 scene.render.filepath = path scene.view_settings.view_transform = "Standard" fcode = gallery_framing.check_framing( scene, cam, hero=[low], elements=[low], stage=[floor, wall], ) if fcode: return fcode bpy.ops.render.render(write_still=True) if not (os.path.exists(path) and os.path.getsize(path) > 0): return fail("render produced no file", 14) return 0 def main(): argv = sys.argv[sys.argv.index("--") + 1:] if "--" in sys.argv else [] p = argparse.ArgumentParser() p.add_argument("--output", default=None) p.add_argument("--engine", default="eevee", choices=("eevee", "cycles")) p.add_argument("--skip-decimate", action="store_true") p.add_argument("--stray-vert", action="store_true") p.add_argument("--lift-z", action="store_true") p.add_argument("--short-feet", action="store_true") p.add_argument("--low-brace", action="store_true") p.add_argument("--float-awning", action="store_true") p.add_argument("--rake-posts", action="store_true") args = p.parse_args(argv) code, low, _high, wood, tex, _col = check( args.skip_decimate, lift_z=args.lift_z, stray_vert=args.stray_vert, short_feet=args.short_feet, low_brace=args.low_brace, float_awning=args.float_awning, rake_posts=args.rake_posts, ) if code: return code if args.output: rcode = render_still(low, wood, tex, os.path.abspath(args.output), args.engine) if rcode: return rcode print(f"rendered still {args.output}") print("market-stall OK") return 0 if __name__ == "__main__": try: sys.exit(main()) except Exception as e: traceback.print_exc() print(f"FATAL: {e}", file=sys.stderr) sys.exit(1)