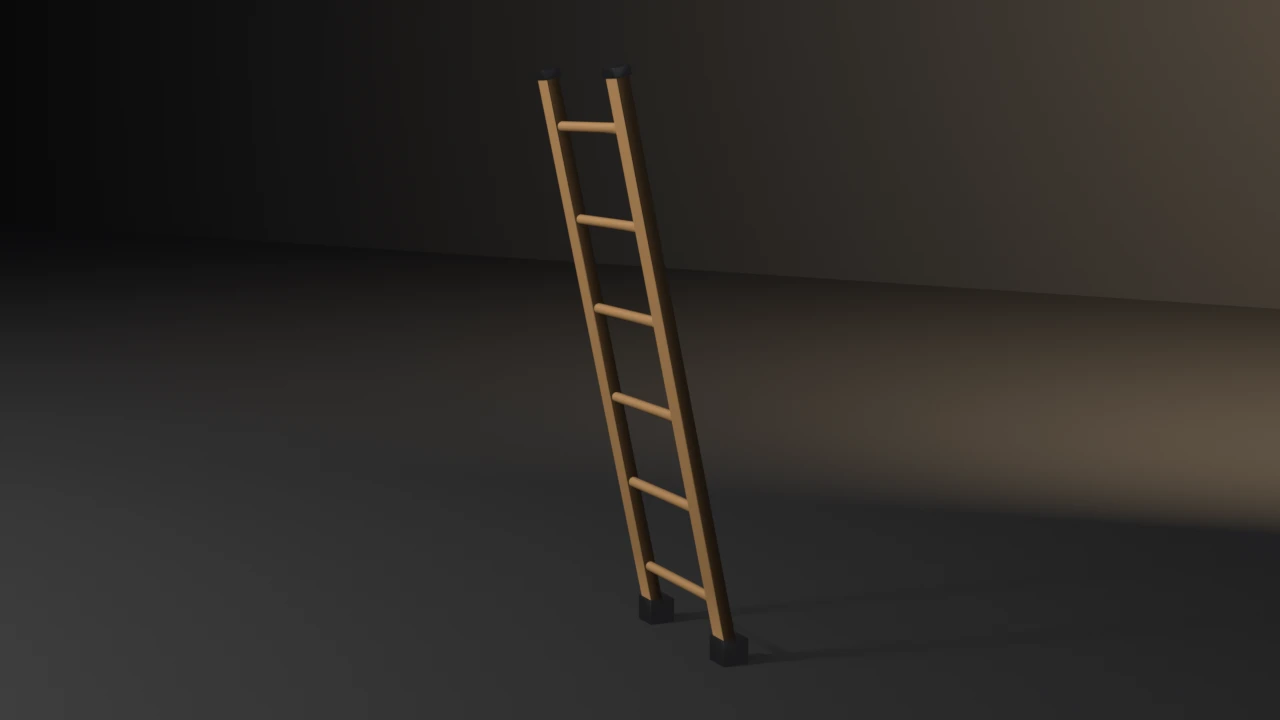
Rendered headless by the example itself — click to zoom.
blender --background --python showcase/wooden-ladder/wooden_ladder.py --
A showcase piece, not an example. Procedural timber ladder (raked stiles, six 26 mm dowel rungs tenoned into the stiles, iron shoes and top caps) then the shipped pipeline: unique-cell UVs, Cycles high-to-low normal bake, LOD chain, convex collider, Unity glTF export.
It asserts budget conformance of the generated result. It does not witness an API contract. "It rendered without error" is not a check.
Composes skills mesh-editing-and-bmesh, bake-high-to-low, depsgraph-and-evaluated-data, engine-export-presets, and snippets bake_normal_high_to_low.py, setup_bake_target_image.py, lod_chain.py / decimate_to_budget.py, convex_hull_collider.py, export_preset_unity.py (helpers copied, not imported as a package).
Budgets
Declared as named constants; every gate recomputes from the mesh, materials, UVs, evaluated LOD, collider, or export file.
| Axis | Declared | Measured (4.5.11 / 5.1.2 / 5.2.1) | | --- | --- | --- | | Base triangles | 900–975 | 936 / 936 / 936 | | LOD1 ratio | 0.32–0.62 of base | 0.5000 / 0.5000 / 0.5000 | | LOD2 ratio | 0.10–0.35 of base | 0.2179 / 0.2179 / 0.2179 | | Materials | exactly 2 distinct, ≥280 wood, ≥180 metal | 2 slots, 324 wood, 216 metal | | UVs | in 0..1, AABB overlap ≤ 1e-5 | in range, overlap 0 | | Outer AABB | (0.472, 0.365, 1.460) m ± 0.01 | (0.4720, 0.3649, 1.4597) | | Grounded | abs(zmin) ≤ 1e-4 | 0.0000 | | Mesh hygiene | non-manifold, loose v/e, doubles at 1e-5, zero-area, n-gons all 0 | all 0 | | Parts | exactly 12 shells (2 stiles, 6 rungs, 2 caps, 2 shoes) | 12 (2 / 6) | | Rung depth clearance | ≥ 0.003 m inside the stile faces | 0.00361 | | Tenon engagement | ≥ 0.006 m past the stile inner face | 0.01200 | | Tenon breakout margin | ≥ 0.005 m short of the stile outer face | 0.04600 | | Collider tris | ≤ 120 | 24 | | Export | written, size > 0 | 75140 / 75140 / 75128 bytes |
Base triangles fell from 2184 to 936 in the quality pass: four iron fittings per stile collapsed to one shoe and one top cap, and the redundant top block came out. No hidden-face removal was involved.
The rung rims are capped and buried in the stile rather than left open. That costs 144 tris nobody sees, but an open rim is a non-manifold boundary and the hygiene budget forbids it.
The joint budgets are measured per rung against each stile, from vertex positions in the un-raked construction frame, and the reported value is the worst case over all twelve rung ends. clearance is how far the widest dowel stays inside the stile's front and back faces; it must exceed the 2.5 mm chamfer or the dowel erupts through it as a spike.
DECIMATE COLLAPSE triangle counts are not identical across series — the gate is a ratio band, not an exact count. On this mesh the three binaries agreed on LOD ratios. Bake pixels are stochastic; the gate is has_data plus operator FINISHED, not byte-identity. Construction uses no RNG. Export byte counts differ by 16 B on 5.2.1 (glTF serializer), not a gated axis.
Each falsifier violates exactly one named budget, and each was proven to fire on all three binaries:
| Falsifier | Budget violated | Exit | Measured failure | | --- | --- | --- | --- | | --skip-decimate | LOD1 ratio band | 9 | ratio 1.0000 | | --stray-vert | Mesh hygiene, loose verts | 15 | loose_v=1 | | --lift-z | Grounded zmin | 16 | zmin 0.050000 | | --fat-rungs | Rung depth clearance | 17 | clearance −0.00051 |
--fat-rungs widens the dowels to the full 34 mm stile depth, which is the proportion this piece shipped with before the quality pass.
Run
blender --background --python wooden_ladder.py --
blender --background --python wooden_ladder.py -- --skip-decimate
blender --background --python wooden_ladder.py -- --stray-vert
blender --background --python wooden_ladder.py -- --lift-z
blender --background --python wooden_ladder.py -- --fat-rungs
blender --background --python wooden_ladder.py -- --output ladder.png
Smoke passes no flags: no --output, no falsifier.
Exit codes
File-local. 9 is a valid check code. 10 is reserved for gallery_framing.check_framing on the --output path.
| Code | Meaning | | --- | --- | | 0 | Success | | 1 | Uncaught exception (FATAL wrapper) | | 2 | argparse / usage | | 3 | Mesh did not build / no UV layer | | 4 | Base triangle count outside range | | 5 | Material count ≠ 2 distinct slots, or wood/metal faces missing | | 6 | UVs outside 0..1 | | 7 | UV AABB overlap above tolerance | | 8 | World AABB off declared outer size | | 9 | LOD ratio band (--skip-decimate lands here) | | 10 | Framing gate (render path only) | | 11 | Collider triangle count above ceiling | | 12 | Bake did not finish or image has no data | | 13 | Export file missing or empty | | 14 | --output produced no file | | 15 | Mesh hygiene (--stray-vert lands here) | | 16 | World AABB min Z off the floor (--lift-z lands here) | | 17 | Part count or rung-to-stile joint fit (--fat-rungs lands here) |
Source
"""Game-ready wooden ladder — a showcase piece, not an example. Asserts budget conformance of a procedural timber ladder after composing shipped pipeline pieces: bmesh construction, UVs, two materials, high-to-low normal bake, LOD chain, convex collider, Unity glTF export. Budgets are declared below and recomputed from the generated result. They are not API-contract witnesses. Each falsifier violates exactly one named budget: ``--skip-decimate`` skips the LOD DECIMATE stage so the LOD-ratio budget fails, ``--lift-z`` moves the mesh off the floor so the grounded budget fails, ``--stray-vert`` adds one unconnected vertex so the mesh-hygiene budget fails, and ``--fat-rungs`` widens the dowels to the full stile depth so the rung-to-stile joint-fit budget fails. No RNG. Construction is closed-form. DECIMATE COLLAPSE triangle counts are not byte-identical across Blender versions — the LOD gate is a ratio band, not an exact count. blender --background --python wooden_ladder.py -- blender --background --python wooden_ladder.py -- --skip-decimate blender --background --python wooden_ladder.py -- --lift-z blender --background --python wooden_ladder.py -- --stray-vert blender --background --python wooden_ladder.py -- --fat-rungs blender --background --python wooden_ladder.py -- --output ladder.png """ import argparse import math import os import sys import tempfile import traceback import bmesh import bpy from mathutils import Euler, Vector # Showcase lives at repo-root/showcase/, not under examples/. The framing # helper is the repo's only shared import and lives next to the examples; # resolve the repo root so we do not move gallery_framing.py. _REPO = os.path.abspath( os.path.join(os.path.dirname(os.path.abspath(__file__)), os.pardir, os.pardir) ) sys.path.insert(0, os.path.join(_REPO, "examples")) sys.dont_write_bytecode = True import gallery_framing # noqa: E402 STILE_H = 1.48 STILE_W = 0.058 STILE_D = 0.034 SPAN = 0.34 N_RUNGS = 6 # A 26 mm dowel in a 34 mm stile. Sized so the widest rung still clears the # stile's 2.5 mm chamfer by more than a millimetre; at 17 mm the dowel was as # deep as the stile and broke through the front and back chamfers as a spike. RUNG_R = 0.013 RUNG_SEGS = 12 RUNG_TENON = 0.012 RUNG_RADIUS_SCALE = (0.98, 1.02, 0.99, 1.03, 0.97, 1.01) RUNG_Z_OFFSETS = (0.0, 0.0015, -0.0010, 0.0010, -0.0015, 0.0) TOP_CAP_H = 0.025 SHOE_H = 0.065 SHOE_W = 0.074 SHOE_D = 0.070 RAKE = math.radians(12.0) BBOX_TOL = 0.01 # 2 stiles + 6 rungs + 2 top caps + 2 shoes, each a closed shell. PART_COUNT = 12 # Measured joint contract. Clearance exceeds the 2.5 mm chamfer so the dowel # stays on the stile's flat face; engagement keeps the tenon seated; breakout # keeps it from reaching the outer face. RUNG_DEPTH_CLEARANCE = 0.003 TENON_ENGAGE_MIN = 0.006 TENON_BREAKOUT_MIN = 0.005 ZMIN_EPS = 1e-4 DOUBLES_EPS = 1e-5 AREA_EPS = 1e-10 LIFT_Z = 0.05 # Fitted after locking geometry. Recomputed from bound_box. OUTER_SIZE = (0.472, 0.365, 1.460) BASE_TRIS_MIN = 900 BASE_TRIS_MAX = 975 LOD1_RATIO_MIN = 0.32 LOD1_RATIO_MAX = 0.62 LOD2_RATIO_MIN = 0.10 LOD2_RATIO_MAX = 0.35 LOD1_TARGET = 0.50 LOD2_TARGET = 0.22 MATERIAL_COUNT = 2 UV_EPS = 1e-4 UV_OVERLAP_MAX = 1e-5 COLLIDER_TRIS_MAX = 120 BAKE_RES = 256 CAGE_EXTRUSION = 0.06 # The caps and shoes carry far more chamfer than body faces, so a floor above # their 24 unbevelled box faces is what catches a bevel whose new faces fell # back to the wood slot. METAL_FACES_MIN = 180 WOOD_FACES_MIN = 280 WOOD_IDX = 0 METAL_IDX = 1 def eevee_engine_id(): return "BLENDER_EEVEE" if bpy.app.version >= (5, 0, 0) else "BLENDER_EEVEE_NEXT" def fail(msg, code): print(f"ERROR: {msg}", file=sys.stderr) return code def triangle_count(mesh): mesh.calc_loop_triangles() return len(mesh.loop_triangles) def evaluated_triangle_count(obj): # Duplicated from snippets/lod_chain.py / decimate_to_budget.py (not a package). depsgraph = bpy.context.evaluated_depsgraph_get() eval_obj = obj.evaluated_get(depsgraph) eval_mesh = eval_obj.to_mesh() try: eval_mesh.calc_loop_triangles() return len(eval_mesh.loop_triangles) finally: eval_obj.to_mesh_clear() def add_box(bm, loc, scale, mat_idx, euler=(0.0, 0.0, 0.0)): geo = bmesh.ops.create_cube(bm, size=1.0) verts = geo["verts"] rot = Euler(euler).to_matrix() origin = Vector(loc) for v in verts: p = Vector((v.co.x * scale[0], v.co.y * scale[1], v.co.z * scale[2])) v.co = rot @ p + origin faces = {f for v in verts for f in v.link_faces} for f in faces: f.material_index = mat_idx return verts def add_cone(bm, loc, radius1, radius2, depth, segments, mat_idx, euler=(0.0, 0.0, 0.0)): geo = bmesh.ops.create_cone( bm, cap_ends=True, cap_tris=True, segments=segments, radius1=radius1, radius2=radius2, depth=depth, ) verts = list(geo["verts"]) rot = Euler(euler).to_matrix() origin = Vector(loc) for v in verts: v.co = rot @ v.co + origin faces = {f for v in verts for f in v.link_faces} for f in faces: f.material_index = mat_idx return verts def add_cylinder(bm, loc, radius, depth, segments, mat_idx, euler=(0.0, 0.0, 0.0)): return add_cone(bm, loc, radius, radius, depth, segments, mat_idx, euler=euler) def pack_uvs(bm, margin=0.08): uv = bm.loops.layers.uv.new("UVMap") faces = list(bm.faces) n = len(faces) cols = max(1, math.ceil(math.sqrt(n))) rows = max(1, math.ceil(n / cols)) cell_w = 1.0 / cols cell_h = 1.0 / rows pad_u = margin * cell_w * 0.5 pad_v = margin * cell_h * 0.5 usable_w = cell_w - 2.0 * pad_u usable_h = cell_h - 2.0 * pad_v for i, face in enumerate(faces): col = i % cols row = i // cols nrm = face.normal ax = abs(nrm.x) ay = abs(nrm.y) az = abs(nrm.z) coords = [] for loop in face.loops: co = loop.vert.co if az >= ax and az >= ay: coords.append((co.x, co.y)) elif ax >= ay: coords.append((co.y, co.z)) else: coords.append((co.x, co.z)) xs = [c[0] for c in coords] ys = [c[1] for c in coords] minx, maxx = min(xs), max(xs) miny, maxy = min(ys), max(ys) dx = max(maxx - minx, 1e-8) dy = max(maxy - miny, 1e-8) origin_u = col * cell_w + pad_u origin_v = row * cell_h + pad_v for loop, (x, y) in zip(face.loops, coords): loop[uv].uv = ( origin_u + (x - minx) / dx * usable_w, origin_v + (y - miny) / dy * usable_h, ) def build_ladder_mesh(name, bevel_offset, bevel_segments, rung_radius=RUNG_R): bm = bmesh.new() stile_verts = [] metal_faces = set() metal_verts = [] try: half = SPAN / 2.0 + STILE_W / 2.0 for sign in (-1.0, 1.0): stile_verts.extend( add_box( bm, (sign * half, 0.0, STILE_H / 2.0), (STILE_W, STILE_D, STILE_H), WOOD_IDX, ) ) z0 = 0.16 z1 = STILE_H - 0.14 for i in range(N_RUNGS): t = i / (N_RUNGS - 1) z = z0 + t * (z1 - z0) + RUNG_Z_OFFSETS[i] # Tenons stop inside the stile, so the rung rims never reach the # chamfered outer face. Rungs stay unbeveled: they are already # round, and beveling a cap rim spikes through that chamfer. add_cylinder( bm, (0.0, 0.0, z), rung_radius * RUNG_RADIUS_SCALE[i], SPAN + 2.0 * RUNG_TENON, RUNG_SEGS, WOOD_IDX, euler=(0.0, math.pi / 2.0, 0.0), ) if bevel_offset > 0.0: edges = list( { edge for vertex in stile_verts for edge in vertex.link_edges if vertex.is_valid } ) if edges: bmesh.ops.bevel( bm, geom=edges, offset=bevel_offset, segments=bevel_segments, profile=0.5, affect="EDGES", clamp_overlap=True, ) before = set(bm.faces) for sign in (-1.0, 1.0): hx = sign * half metal_verts.extend( add_box( bm, (hx, 0.0, STILE_H - TOP_CAP_H * 0.30), (STILE_W + 0.010, STILE_D + 0.010, TOP_CAP_H), METAL_IDX, ) ) metal_faces.update(set(bm.faces) - before) rake = Euler((RAKE, 0.0, 0.0)).to_matrix() for v in bm.verts: v.co = rake @ v.co zs = [v.co.z for v in bm.verts] zmin = min(zs) xs = [v.co.x for v in bm.verts] ys = [v.co.y for v in bm.verts] cx = 0.5 * (min(xs) + max(xs)) cy = 0.5 * (min(ys) + max(ys)) for v in bm.verts: v.co.x -= cx v.co.y -= cy v.co.z -= zmin before = set(bm.faces) for sign in (-1.0, 1.0): bottom = rake @ Vector((sign * half, 0.0, 0.0)) bottom.x -= cx bottom.y -= cy bottom.z -= zmin metal_verts.extend( add_box( bm, (bottom.x, bottom.y, SHOE_H / 2.0), (SHOE_W, SHOE_D, SHOE_H), METAL_IDX, ) ) metal_faces.update(set(bm.faces) - before) if bevel_offset > 0.0: metal_edges = list( { edge for vertex in metal_verts for edge in vertex.link_edges if vertex.is_valid } ) if metal_edges: # Bevel does not inherit material_index onto the faces it # creates, so claim them from the op's own return rather than # from a pre-bevel face snapshot. Without this every chamfer # on a cap or shoe falls back to slot 0 and renders as wood. bevelled = bmesh.ops.bevel( bm, geom=metal_edges, offset=min(bevel_offset, 0.002), segments=bevel_segments, profile=0.5, affect="EDGES", clamp_overlap=True, ) metal_faces.update(bevelled.get("faces") or []) ys = [v.co.y for v in bm.verts] final_cy = 0.5 * (min(ys) + max(ys)) for v in bm.verts: v.co.y -= final_cy pack_uvs(bm) bmesh.ops.recalc_face_normals(bm, faces=list(bm.faces)) for face in bm.faces: face.smooth = True for edge in bm.edges: edge.smooth = True if edge.is_manifold and len(edge.link_faces) == 2: if edge.calc_face_angle() > math.radians(40.0): edge.smooth = False for f in metal_faces: if f.is_valid: f.material_index = METAL_IDX me = bpy.data.meshes.new(name) bm.to_mesh(me) me.update() finally: bm.free() obj = bpy.data.objects.new(name, me) bpy.context.collection.objects.link(obj) return obj def principled(name, color, metallic, roughness): mat = bpy.data.materials.new(name) mat.use_nodes = True bsdf = mat.node_tree.nodes["Principled BSDF"] bsdf.inputs["Base Color"].default_value = color bsdf.inputs["Metallic"].default_value = metallic bsdf.inputs["Roughness"].default_value = roughness return mat def assign_slots(obj, wood, metal): mats = obj.data.materials wanted = (wood, metal) for i, mat in enumerate(wanted): if i < len(mats): mats[i] = mat else: mats.append(mat) def world_bbox(obj): corners = [obj.matrix_world @ Vector(c) for c in obj.bound_box] xs = [c.x for c in corners] ys = [c.y for c in corners] zs = [c.z for c in corners] return (min(xs), min(ys), min(zs), max(xs), max(ys), max(zs)) def face_area(me, poly): vs = [me.vertices[i].co for i in poly.vertices] if len(vs) < 3: return 0.0 v0 = vs[0] area = 0.0 for i in range(1, len(vs) - 1): area += (vs[i] - v0).cross(vs[i + 1] - v0).length * 0.5 return area def hygiene_audit(me): # Combinatorics match examples/mesh-hygiene-audit.audit (copied, not imported). nv, ne, nf = len(me.vertices), len(me.edges), len(me.polygons) ngons = sum(1 for p in me.polygons if len(p.vertices) > 4) areas = [face_area(me, p) for p in me.polygons] zero_area = sum(1 for area in areas if area <= AREA_EPS) bm = bmesh.new() try: bm.from_mesh(me) bm.verts.ensure_lookup_table() bm.edges.ensure_lookup_table() loose_v = sum(1 for v in bm.verts if len(v.link_edges) == 0) loose_e = sum(1 for e in bm.edges if len(e.link_faces) == 0) nonman = sum(1 for e in bm.edges if not e.is_manifold) ret = bmesh.ops.find_doubles(bm, verts=list(bm.verts), dist=DOUBLES_EPS) doubles = len(ret.get("targetmap") or {}) finally: bm.free() return { "nv": nv, "ne": ne, "nf": nf, "ngons": ngons, "loose_v": loose_v, "loose_e": loose_e, "nonman": nonman, "zero_area": zero_area, "doubles": doubles, "euler": nv - ne + nf, } def mesh_components(me): """Per-part AABBs in the construction frame, un-raked so the stiles read axis-aligned. The parts interpenetrate but share no vertices, so edge connectivity separates them.""" neighbors = [[] for _ in range(len(me.vertices))] for edge in me.edges: a, b = edge.vertices neighbors[a].append(b) neighbors[b].append(a) unrake = Euler((-RAKE, 0.0, 0.0)).to_matrix() seen = [False] * len(me.vertices) parts = [] for start in range(len(me.vertices)): if seen[start]: continue seen[start] = True stack = [start] points = [] while stack: current = stack.pop() points.append(unrake @ me.vertices[current].co) for nxt in neighbors[current]: if not seen[nxt]: seen[nxt] = True stack.append(nxt) lo = Vector( ( min(p.x for p in points), min(p.y for p in points), min(p.z for p in points), ) ) hi = Vector( ( max(p.x for p in points), max(p.y for p in points), max(p.z for p in points), ) ) parts.append((lo, hi)) return parts def joint_audit(me): """Worst-case rung-to-stile fit, recomputed from vertex positions.""" parts = mesh_components(me) stiles = [p for p in parts if (p[1].z - p[0].z) > STILE_H * 0.8] rungs = [p for p in parts if (p[1].x - p[0].x) > SPAN] if len(stiles) != 2 or len(rungs) != N_RUNGS: return { "parts": len(parts), "stiles": len(stiles), "rungs": len(rungs), "clearance": -1.0, "engage": -1.0, "breakout": -1.0, } left = min(stiles, key=lambda p: p[0].x) right = max(stiles, key=lambda p: p[0].x) clearance = min( min( (stile[1].y - stile[0].y) - (rung[1].y - rung[0].y) for stile in (left, right) ) * 0.5 for rung in rungs ) engage = min( min(left[1].x - rung[0].x, rung[1].x - right[0].x) for rung in rungs ) breakout = min( min(rung[0].x - left[0].x, right[1].x - rung[1].x) for rung in rungs ) return { "parts": len(parts), "stiles": len(stiles), "rungs": len(rungs), "clearance": clearance, "engage": engage, "breakout": breakout, } def add_stray_vert(me): # Falsification only: one unconnected vertex, placed inside the existing # bounds so the bbox budget still passes and the hygiene budget is the # gate that fires. bm = bmesh.new() try: bm.from_mesh(me) bm.verts.new((0.0, 0.0, STILE_H / 3.0)) bm.to_mesh(me) me.update() finally: bm.free() def uv_stats(mesh): uv = mesh.uv_layers.active if uv is None: return 0.0, 0.0, 1.0, 1.0, 0, 1.0 data = uv.data us = [loop.uv[0] for loop in data] vs = [loop.uv[1] for loop in data] aabbs = [] for poly in mesh.polygons: pu = [data[i].uv[0] for i in poly.loop_indices] pv = [data[i].uv[1] for i in poly.loop_indices] aabbs.append((min(pu), min(pv), max(pu), max(pv))) overlap = 0.0 for i in range(len(aabbs)): a = aabbs[i] for j in range(i + 1, len(aabbs)): b = aabbs[j] x0 = max(a[0], b[0]) y0 = max(a[1], b[1]) x1 = min(a[2], b[2]) y1 = min(a[3], b[3]) overlap += max(0.0, x1 - x0) * max(0.0, y1 - y0) return min(us), min(vs), max(us), max(vs), overlap, len(aabbs) def make_lod(obj, name, ratio, skip_decimate): mesh = obj.data.copy() lod = bpy.data.objects.new(name, mesh) lod.matrix_world = obj.matrix_world.copy() bpy.context.scene.collection.objects.link(lod) if not skip_decimate and 0.0 < ratio < 1.0: mod = lod.modifiers.new("DecimateBudget", "DECIMATE") mod.decimate_type = "COLLAPSE" mod.ratio = ratio return lod def convex_hull_collider(obj, name): # Duplicated from snippets/convex_hull_collider.py (not a package). mesh = bpy.data.meshes.new(name) bm = bmesh.new() try: bm.from_mesh(obj.data) result = bmesh.ops.convex_hull(bm, input=list(bm.verts)) interior = result.get("geom_interior") or [] unused = result.get("geom_unused") or [] if interior: bmesh.ops.delete(bm, geom=interior, context="VERTS") if unused: bmesh.ops.delete(bm, geom=unused, context="VERTS") bm.to_mesh(mesh) mesh.update() finally: bm.free() collider = bpy.data.objects.new(name, mesh) bpy.context.collection.objects.link(collider) collider.matrix_world = obj.matrix_world.copy() return collider def setup_bake_image(obj, target_mat, size=BAKE_RES): # Adapted from snippets/setup_bake_target_image.py — do not replace slots. if not obj.data.uv_layers: return None, None img = bpy.data.images.new("LadderNrm", size, size, alpha=True, float_buffer=False) img.colorspace_settings.name = "Non-Color" nodes = target_mat.node_tree.nodes tex = nodes.new("ShaderNodeTexImage") tex.image = img nodes.active = tex tex.select = True obj.active_material_index = WOOD_IDX return img, tex def bake_normal(high, low): # Duplicated from snippets/bake_normal_high_to_low.py (not a package). scene = bpy.context.scene scene.render.engine = "CYCLES" scene.cycles.device = "CPU" scene.cycles.samples = 1 scene.cycles.use_denoising = False for ob in bpy.context.view_layer.objects: ob.select_set(False) high.select_set(True) low.select_set(True) bpy.context.view_layer.objects.active = low return bpy.ops.object.bake( type="NORMAL", use_selected_to_active=True, cage_extrusion=CAGE_EXTRUSION, use_cage=False, normal_space="TANGENT", margin=4, margin_type="ADJACENT_FACES", use_clear=True, target="IMAGE_TEXTURES", ) def export_unity(path, objects): # Duplicated from snippets/export_preset_unity.py (not a package). for ob in bpy.context.view_layer.objects: ob.select_set(False) for ob in objects: ob.select_set(True) bpy.context.view_layer.objects.active = objects[0] bpy.ops.export_scene.gltf( filepath=path, use_selection=True, export_yup=True, export_apply=True, export_draco_mesh_compression_enable=False, export_animations=False, ) def check(skip_decimate, lift_z=False, stray_vert=False, fat_rungs=False): bpy.ops.wm.read_factory_settings(use_empty=True) # Falsification: a dowel as deep as the stile, which is what used to break # through the front and back chamfers. rung_radius = STILE_D / 2.0 if fat_rungs else RUNG_R low = build_ladder_mesh( "LadderLow", bevel_offset=0.0025, bevel_segments=2, rung_radius=rung_radius ) high = build_ladder_mesh( "LadderHigh", bevel_offset=0.0025, bevel_segments=4, rung_radius=rung_radius ) if lift_z: low.location.z += LIFT_Z if stray_vert: add_stray_vert(low.data) # world_bbox reads matrix_world, which is evaluated data. Without this the # cached matrix hides a moved object and the grounded budget cannot fail. bpy.context.view_layer.update() wood = principled("LadderWood", (0.42, 0.24, 0.10, 1.0), 0.0, 0.55) metal = principled("LadderMetal", (0.48, 0.46, 0.42, 1.0), 1.0, 0.28) assign_slots(low, wood, metal) assign_slots(high, wood, metal) if low.data is None or len(low.data.polygons) < 6: return fail("ladder mesh did not build", 3), None, None, None, None, None base_tris = triangle_count(low.data) mats = [s for s in low.data.materials if s is not None] nmat = len(mats) distinct_mats = len({id(s) for s in mats}) idx_counts = {} for poly in low.data.polygons: idx_counts[poly.material_index] = idx_counts.get(poly.material_index, 0) + 1 print(f"measured mat_index_counts={idx_counts}") u0, v0, u1, v1, overlap, nfaces = uv_stats(low.data) bb = world_bbox(low) size_x = bb[3] - bb[0] size_y = bb[4] - bb[1] size_z = bb[5] - bb[2] img, tex = setup_bake_image(low, wood) if img is None: return fail("ladder has no UV layer", 3), None, None, None, None, None bake_result = bake_normal(high, low) lod1 = make_lod(low, "LadderLOD1", LOD1_TARGET, skip_decimate) lod2 = make_lod(low, "LadderLOD2", LOD2_TARGET, skip_decimate) bpy.context.view_layer.update() lod1_tris = evaluated_triangle_count(lod1) lod2_tris = evaluated_triangle_count(lod2) r1 = lod1_tris / base_tris if base_tris else 0.0 r2 = lod2_tris / base_tris if base_tris else 0.0 collider_src = build_ladder_mesh("LadderColSrc", bevel_offset=0.0, bevel_segments=1) collider = convex_hull_collider(collider_src, "LadderCollider") bpy.data.objects.remove(collider_src, do_unlink=True) col_tris = triangle_count(collider.data) export_path = os.path.join( tempfile.gettempdir(), f"bdt_wooden_ladder_{os.getpid()}.glb", ) if os.path.exists(export_path): os.remove(export_path) export_unity(export_path, [low, collider]) export_size = os.path.getsize(export_path) if os.path.isfile(export_path) else 0 print( f"blender={tuple(bpy.app.version)} skip_decimate={skip_decimate}" ) print( f"measured base_tris={base_tris} lod1_tris={lod1_tris} " f"lod2_tris={lod2_tris} r1={r1:.4f} r2={r2:.4f}" ) print( f"measured nmat={nmat} uv=({u0:.4f},{v0:.4f})-({u1:.4f},{v1:.4f}) " f"overlap={overlap:.6f} nfaces={nfaces}" ) print( f"measured bbox=({size_x:.4f},{size_y:.4f},{size_z:.4f}) " f"outer={OUTER_SIZE} zmin={bb[2]:.4f}" ) print( f"measured collider_tris={col_tris} bake={bake_result} " f"bake_has_data={img.has_data} export_bytes={export_size}" ) hyg = hygiene_audit(low.data) print( f"measured hygiene loose_v={hyg['loose_v']} loose_e={hyg['loose_e']} " f"nonman={hyg['nonman']} zero_area={hyg['zero_area']} " f"doubles={hyg['doubles']} ngons={hyg['ngons']} euler={hyg['euler']}" ) joint = joint_audit(low.data) print( f"measured joints parts={joint['parts']} stiles={joint['stiles']} " f"rungs={joint['rungs']} clearance={joint['clearance']:.5f} " f"engage={joint['engage']:.5f} breakout={joint['breakout']:.5f}" ) if not (BASE_TRIS_MIN <= base_tris <= BASE_TRIS_MAX): return fail( f"base tris {base_tris} not in [{BASE_TRIS_MIN}, {BASE_TRIS_MAX}]", 4, ), None, None, None, None, None if nmat != MATERIAL_COUNT or distinct_mats != MATERIAL_COUNT: return fail( f"material slots {nmat} distinct {distinct_mats} != {MATERIAL_COUNT}", 5, ), None, None, None, None, None if idx_counts.get(WOOD_IDX, 0) < WOOD_FACES_MIN: return fail( f"wood faces {idx_counts.get(WOOD_IDX, 0)} < {WOOD_FACES_MIN}", 5, ), None, None, None, None, None if idx_counts.get(METAL_IDX, 0) < METAL_FACES_MIN: return fail( f"metal faces {idx_counts.get(METAL_IDX, 0)} < {METAL_FACES_MIN}", 5, ), None, None, None, None, None if u0 < -UV_EPS or v0 < -UV_EPS or u1 > 1.0 + UV_EPS or v1 > 1.0 + UV_EPS: return fail( f"UVs outside 0..1: ({u0:.4f},{v0:.4f})-({u1:.4f},{v1:.4f})", 6, ), None, None, None, None, None if overlap > UV_OVERLAP_MAX: return fail( f"UV AABB overlap {overlap:.6f} > {UV_OVERLAP_MAX}", 7, ), None, None, None, None, None if ( abs(size_x - OUTER_SIZE[0]) > BBOX_TOL or abs(size_y - OUTER_SIZE[1]) > BBOX_TOL or abs(size_z - OUTER_SIZE[2]) > BBOX_TOL ): return fail( f"bbox ({size_x:.4f},{size_y:.4f},{size_z:.4f}) " f"off outer {OUTER_SIZE}", 8, ), None, None, None, None, None if not (LOD1_RATIO_MIN <= r1 <= LOD1_RATIO_MAX): return fail( f"LOD1 ratio {r1:.4f} not in [{LOD1_RATIO_MIN}, {LOD1_RATIO_MAX}] " "(--skip-decimate is the designed fail)", 9, ), None, None, None, None, None if not (LOD2_RATIO_MIN <= r2 <= LOD2_RATIO_MAX): return fail( f"LOD2 ratio {r2:.4f} not in [{LOD2_RATIO_MIN}, {LOD2_RATIO_MAX}]", 9, ), None, None, None, None, None if col_tris > COLLIDER_TRIS_MAX: return fail( f"collider tris {col_tris} > {COLLIDER_TRIS_MAX}", 11, ), None, None, None, None, None if bake_result != {"FINISHED"} or not img.has_data: return fail( f"bake failed result={bake_result} has_data={img.has_data}", 12, ), None, None, None, None, None if export_size <= 0: return fail("export file missing or empty", 13), None, None, None, None, None if ( hyg["loose_v"] or hyg["loose_e"] or hyg["nonman"] or hyg["zero_area"] or hyg["doubles"] or hyg["ngons"] ): return fail( f"hygiene loose_v={hyg['loose_v']} loose_e={hyg['loose_e']} " f"nonman={hyg['nonman']} zero_area={hyg['zero_area']} " f"doubles={hyg['doubles']} ngons={hyg['ngons']}", 15, ), None, None, None, None, None if abs(bb[2]) > ZMIN_EPS: return fail( f"zmin {bb[2]:.6f} not within {ZMIN_EPS} of 0 " "(--lift-z is the designed fail)", 16, ), None, None, None, None, None if joint["parts"] != PART_COUNT: return fail( f"part count {joint['parts']} != {PART_COUNT} " f"(stiles={joint['stiles']} rungs={joint['rungs']})", 17, ), None, None, None, None, None if joint["clearance"] < RUNG_DEPTH_CLEARANCE: return fail( f"rung-to-stile depth clearance {joint['clearance']:.5f} < " f"{RUNG_DEPTH_CLEARANCE} (--fat-rungs is the designed fail)", 17, ), None, None, None, None, None if joint["engage"] < TENON_ENGAGE_MIN: return fail( f"tenon engagement {joint['engage']:.5f} < {TENON_ENGAGE_MIN}", 17, ), None, None, None, None, None if joint["breakout"] < TENON_BREAKOUT_MIN: return fail( f"tenon breakout margin {joint['breakout']:.5f} < " f"{TENON_BREAKOUT_MIN}", 17, ), None, None, None, None, None return 0, low, high, wood, tex, collider def wire_normal(mat, tex): nt = mat.node_tree bsdf = nt.nodes["Principled BSDF"] nrm = nt.nodes.new("ShaderNodeNormalMap") nrm.inputs["Strength"].default_value = 1.0 nt.links.new(tex.outputs["Color"], nrm.inputs["Color"]) nt.links.new(nrm.outputs["Normal"], bsdf.inputs["Normal"]) def render_still(low, wood, tex, path, engine): scene = bpy.context.scene wire_normal(wood, tex) for ob in list(scene.objects): if ob.type == "MESH" and ob != low: ob.hide_render = True ob.hide_viewport = True low.rotation_euler.z = math.radians(-28.0) floor_me = bpy.data.meshes.new("Floor") bm = bmesh.new() try: # Oversized so no edge of the set can enter frame; the committed hero # used to show the wall's left edge as a bright band in the corner. bmesh.ops.create_grid(bm, x_segments=1, y_segments=1, size=60.0) bm.to_mesh(floor_me) finally: bm.free() fmat = bpy.data.materials.new("Floor") fmat.use_nodes = True fb = fmat.node_tree.nodes["Principled BSDF"] fb.inputs["Base Color"].default_value = (0.03, 0.032, 0.037, 1.0) fb.inputs["Roughness"].default_value = 0.7 floor_me.materials.append(fmat) floor = bpy.data.objects.new("Floor", floor_me) scene.collection.objects.link(floor) wall = bpy.data.objects.new("Wall", floor_me.copy()) wall.location = (0.0, 8.5, 0.0) wall.rotation_euler = (math.radians(90), 0.0, 0.0) scene.collection.objects.link(wall) world = bpy.data.worlds.new("World") world.use_nodes = True world.node_tree.nodes["Background"].inputs["Color"].default_value = ( 0.02, 0.021, 0.025, 1.0, ) scene.world = world def light(name, loc, energy, size, col, rot): ld = bpy.data.lights.new(name, "AREA") ld.energy = energy ld.size = size ld.color = col ob = bpy.data.objects.new(name, ld) ob.location = loc ob.rotation_euler = tuple(math.radians(a) for a in rot) scene.collection.objects.link(ob) light("Key", (-3.6, -5.0, 5.4), 660.0, 4.0, (1.0, 0.94, 0.86), (50, 0, -36)) light("Fill", (5.0, -3.4, 2.4), 46.0, 8.0, (0.72, 0.82, 1.0), (62, 0, 50)) light("Wedge", (2.2, 4.0, 3.8), 600.0, 5.5, (1.0, 0.70, 0.40), (-70, 0, 198)) cam_data = bpy.data.cameras.new("Cam") cam_data.lens = 50.0 cam = bpy.data.objects.new("Cam", cam_data) cam.location = (2.55, -3.55, 1.38) scene.collection.objects.link(cam) aim = bpy.data.objects.new("Aim", None) aim.location = (0.0, 0.0, 0.74) scene.collection.objects.link(aim) con = cam.constraints.new("TRACK_TO") con.target = aim con.track_axis = "TRACK_NEGATIVE_Z" con.up_axis = "UP_Y" scene.camera = cam scene.render.engine = "CYCLES" if engine == "cycles" else eevee_engine_id() if engine == "cycles": scene.cycles.samples = 32 scene.cycles.device = "CPU" else: try: scene.eevee.taa_render_samples = 64 except AttributeError: pass scene.render.resolution_x = 1280 scene.render.resolution_y = 720 scene.render.image_settings.file_format = ( "WEBP" if path.lower().endswith(".webp") else "PNG" ) if path.lower().endswith(".webp"): scene.render.image_settings.quality = 90 scene.render.filepath = path scene.view_settings.view_transform = "Standard" fcode = gallery_framing.check_framing( scene, cam, hero=[low], elements=[low], stage=[floor, wall], ) if fcode: return fcode bpy.ops.render.render(write_still=True) if not (os.path.exists(path) and os.path.getsize(path) > 0): return fail("render produced no file", 14) return 0 def main(): argv = sys.argv[sys.argv.index("--") + 1:] if "--" in sys.argv else [] p = argparse.ArgumentParser() p.add_argument("--output", default=None) p.add_argument("--engine", default="eevee", choices=("eevee", "cycles")) p.add_argument( "--skip-decimate", action="store_true", help="falsification: skip the LOD DECIMATE stage", ) p.add_argument( "--lift-z", action="store_true", help="falsification: lift the mesh so zmin fails the grounded budget", ) p.add_argument( "--stray-vert", action="store_true", help="falsification: add a loose vertex so the hygiene budget fails", ) p.add_argument( "--fat-rungs", action="store_true", help="falsification: dowels as deep as the stile, failing joint fit", ) args = p.parse_args(argv) code, low, _high, wood, tex, _col = check( args.skip_decimate, lift_z=args.lift_z, stray_vert=args.stray_vert, fat_rungs=args.fat_rungs, ) if code: return code if args.output: rcode = render_still(low, wood, tex, os.path.abspath(args.output), args.engine) if rcode: return rcode print(f"rendered still {args.output}") print("wooden-ladder OK") return 0 if __name__ == "__main__": try: sys.exit(main()) except Exception as e: traceback.print_exc() print(f"FATAL: {e}", file=sys.stderr) sys.exit(1)