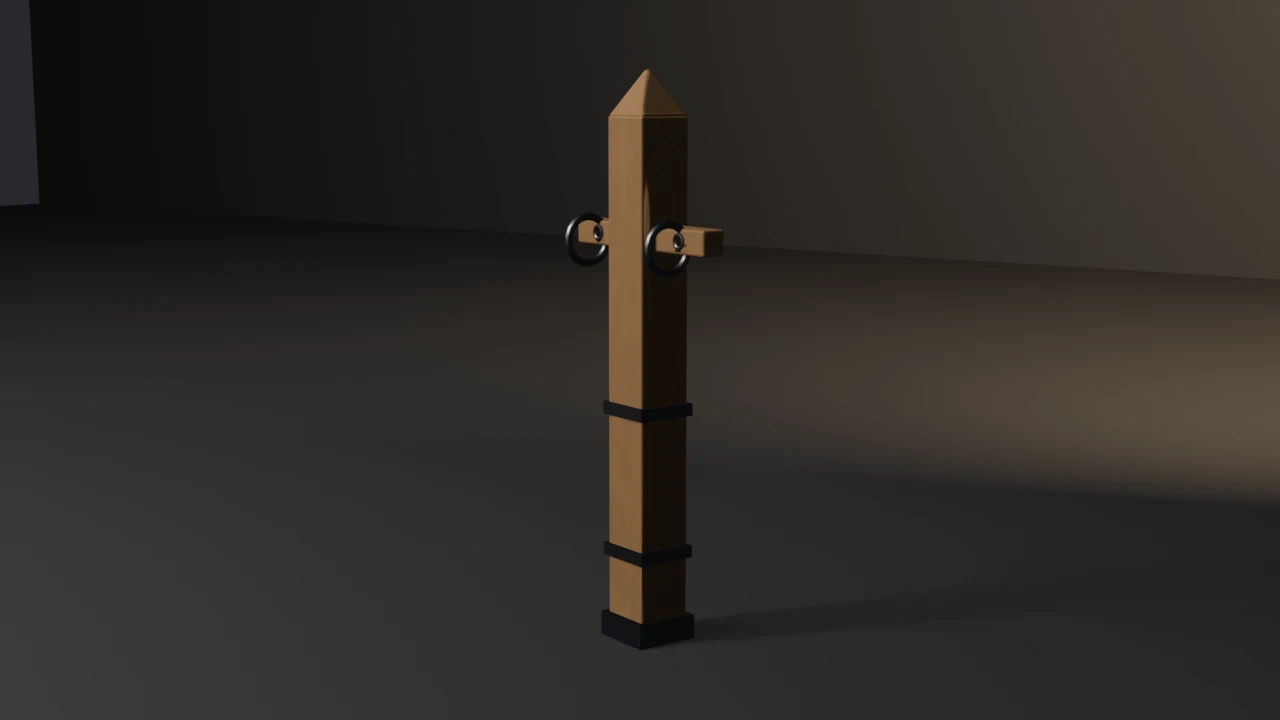
Rendered headless by the example itself — click to zoom.
blender --background --python showcase/hitching-post/hitching_post.py --
A showcase piece, not an example. Procedural timber hitching post (square post, pyramid cap on the post corners, stub-and-tenon cross-arm, iron collar shoe and bands, eye-threaded hitching rings) then the shipped pipeline: unique-cell UVs, Cycles high-to-low normal bake, LOD chain, convex collider, Unity glTF export.
It asserts budget conformance of the generated result. It does not witness an API contract. "It rendered without error" is not a check.
Composes skills mesh-editing-and-bmesh, bake-high-to-low, depsgraph-and-evaluated-data, engine-export-presets, and snippets bake_normal_high_to_low.py, setup_bake_target_image.py, lod_chain.py / decimate_to_budget.py, convex_hull_collider.py, export_preset_unity.py (helpers copied, not imported as a package). Hygiene combinatorics match examples/mesh-hygiene-audit (copied, not imported).
Intended size: 0.125 m square post, 1.16 m timber plus 0.10 m cap; cross-arm 0.46 m; outer AABB 0.460 × 0.191 × 1.258 m.
Budgets
Declared as named constants; every gate recomputes from the mesh, materials, UVs, evaluated LOD, collider, or export file.
| Axis | Declared | Measured (4.5.11 / 5.1.2 / 5.2.1) | | --- | --- | --- | | Base triangles | 900–1800 | 1598 / 1598 / 1598 | | LOD1 ratio | 0.32–0.62 of base | 0.4994 / 0.4994 / 0.4994 | | LOD2 ratio | 0.10–0.35 of base | 0.2190 / 0.2190 / 0.2190 | | Materials | exactly 2 distinct, ≥12 wood, ≥24 metal | 2 slots, 269 wood, 532 metal | | UVs | in 0..1, AABB overlap ≤ 1e-5 | in range, overlap 0 | | Outer AABB | (0.460, 0.191, 1.258) m ± 0.01 | (0.4600, 0.1912, 1.2580) | | Grounded zmin | within 1e-4 of 0 | 0 / 0 / 0 | | Hygiene | loose/nonman/zero-area/doubles/ngons = 0 | 0 / 0 / 0 | | Wood–metal gap | BVH surface < 0.008 m | 0.00045 / 0.00045 / 0.00045 | | Collider tris | ≤ 280 | 78 | | Export | written, size > 0 | 121496 / 121496 / 121480 bytes |
DECIMATE COLLAPSE triangle counts are not identical across series — the gate is a ratio band, not an exact count. Bake pixels are stochastic; the gate is has_data plus operator FINISHED, not byte-identity. Construction uses no RNG. Export byte counts differ by 16 B on 5.2.1 (glTF serializer), not a gated axis. Euler characteristic is 10 (multi-body: timber, collars, eyes, rings) — not gated to 2.
--skip-decimate skips the LOD DECIMATE stage so LOD1 ratio is 1.0 and exit 9 fires. --lift-z raises the mesh 5 cm so the grounded-zmin hygiene budget fails and exit 16 fires.
Run
blender --background --python hitching_post.py --
blender --background --python hitching_post.py -- --skip-decimate
blender --background --python hitching_post.py -- --lift-z
blender --background --python hitching_post.py -- --output hitching-post.png
Smoke does not pass --output, --skip-decimate, or --lift-z.
Exit codes
File-local. 9 is a valid check code. 10 is reserved for gallery_framing.check_framing on the --output path.
| Code | Meaning | | --- | --- | | 0 | Success | | 1 | Uncaught exception (FATAL wrapper) | | 2 | argparse / usage | | 3 | Mesh did not build / no UV layer | | 4 | Base triangle count outside range | | 5 | Material count ≠ 2 distinct slots, or wood/metal faces missing | | 6 | UVs outside 0..1 | | 7 | UV AABB overlap above tolerance | | 8 | World AABB off declared outer size | | 9 | LOD ratio band (--skip-decimate lands here) | | 10 | Framing gate (render path only) | | 11 | Collider triangle count above ceiling | | 12 | Bake did not finish or image has no data | | 13 | Export file missing or empty | | 14 | --output produced no file | | 15 | Hygiene: loose verts/edges, non-manifold, zero-area, doubles, or n-gons | | 16 | Grounded zmin (--lift-z lands here) | | 17 | Wood–metal BVH gap above 8 mm |
Source
"""Game-ready hitching post — a showcase piece, not an example. Asserts budget conformance of a procedural timber hitching post (square post, pyramidal cap, cross-arm, iron shoe, bands, and hitching rings) after composing shipped pipeline pieces: bmesh construction, UVs, two materials, high-to-low normal bake, LOD chain, convex collider, Unity glTF export. Budgets are declared below and recomputed from the generated result. They are not API-contract witnesses. ``--skip-decimate`` skips the LOD DECIMATE stage so the LOD-ratio budget fails. ``--lift-z`` raises the mesh so the grounded-zmin hygiene budget fails. No RNG. Construction is closed-form. DECIMATE COLLAPSE triangle counts are not byte-identical across Blender versions — the LOD gate is a ratio band, not an exact count. blender --background --python hitching_post.py -- blender --background --python hitching_post.py -- --skip-decimate blender --background --python hitching_post.py -- --lift-z blender --background --python hitching_post.py -- --output hitching-post.png """ import argparse import math import os import sys import tempfile import traceback import bmesh import bpy from mathutils import Euler, Vector from mathutils.bvhtree import BVHTree _REPO = os.path.abspath( os.path.join(os.path.dirname(os.path.abspath(__file__)), os.pardir, os.pardir) ) sys.path.insert(0, os.path.join(_REPO, "examples")) sys.dont_write_bytecode = True import gallery_framing # noqa: E402 POST_W = 0.125 POST_H = 1.16 CAP_H = 0.10 CAP_EMBED = 0.002 SHOE_H = 0.055 SHOE_T = 0.014 SHOE_SCALE = 1.38 ARM_Z = 0.90 ARM_L = 0.46 ARM_Y = 0.056 ARM_ZTH = 0.056 TENON_SCALE = 0.62 RING_MAJOR = 0.052 RING_MINOR = 0.009 EYE_MAJOR = 0.015 EYE_MINOR = 0.005 BAND_H = 0.028 BAND_T = 0.010 BAND_ZS = (0.20, 0.52) BBOX_TOL = 0.01 OUTER_SIZE = (0.460, 0.191, 1.258) BASE_TRIS_MIN = 900 BASE_TRIS_MAX = 1800 LOD1_RATIO_MIN = 0.32 LOD1_RATIO_MAX = 0.62 LOD2_RATIO_MIN = 0.10 LOD2_RATIO_MAX = 0.35 LOD1_TARGET = 0.50 LOD2_TARGET = 0.22 MATERIAL_COUNT = 2 UV_EPS = 1e-4 UV_OVERLAP_MAX = 1e-5 COLLIDER_TRIS_MAX = 280 BAKE_RES = 256 CAGE_EXTRUSION = 0.08 METAL_FACES_MIN = 24 WOOD_FACES_MIN = 12 ZMIN_EPS = 1e-4 DOUBLES_EPS = 1e-5 AREA_EPS = 1e-10 GAP_MAX = 0.008 LIFT_Z = 0.05 WOOD_IDX = 0 METAL_IDX = 1 def eevee_engine_id(): return "BLENDER_EEVEE" if bpy.app.version >= (5, 0, 0) else "BLENDER_EEVEE_NEXT" def fail(msg, code): print(f"ERROR: {msg}", file=sys.stderr) return code def triangle_count(mesh): mesh.calc_loop_triangles() return len(mesh.loop_triangles) def evaluated_triangle_count(obj): depsgraph = bpy.context.evaluated_depsgraph_get() eval_obj = obj.evaluated_get(depsgraph) eval_mesh = eval_obj.to_mesh() try: eval_mesh.calc_loop_triangles() return len(eval_mesh.loop_triangles) finally: eval_obj.to_mesh_clear() def deselect_all(): for ob in list(bpy.context.view_layer.objects): if ob is None: continue ob.select_set(False) def add_box(bm, loc, scale, mat_idx, euler=(0.0, 0.0, 0.0)): geo = bmesh.ops.create_cube(bm, size=1.0) verts = geo["verts"] rot = Euler(euler).to_matrix() origin = Vector(loc) for v in verts: p = Vector((v.co.x * scale[0], v.co.y * scale[1], v.co.z * scale[2])) v.co = rot @ p + origin faces = {f for v in verts for f in v.link_faces} for f in faces: f.material_index = mat_idx return verts def add_oriented_box(bm, a, b, scale_xy, mat_idx): a = Vector(a) b = Vector(b) delta = b - a length = delta.length if length < 1e-8: return [] quat = Vector((0.0, 0.0, 1.0)).rotation_difference(delta.normalized()) eul = quat.to_euler("XYZ") return add_box( bm, ((a + b) * 0.5), (scale_xy[0], scale_xy[1], length), mat_idx, euler=(eul.x, eul.y, eul.z), ) def add_cyl(bm, loc, radius, depth, segments, mat_idx, euler=(0.0, 0.0, 0.0)): geo = bmesh.ops.create_cone( bm, cap_ends=True, cap_tris=False, segments=segments, radius1=radius, radius2=radius, depth=depth, ) verts = geo["verts"] rot = Euler(euler).to_matrix() origin = Vector(loc) for v in verts: v.co = rot @ v.co + origin faces = {f for v in verts for f in v.link_faces} for f in faces: f.material_index = mat_idx return verts def add_cone(bm, loc, radius1, radius2, depth, segments, mat_idx, euler=(0.0, 0.0, 0.0)): geo = bmesh.ops.create_cone( bm, cap_ends=True, cap_tris=False, segments=segments, radius1=radius1, radius2=radius2, depth=depth, ) verts = geo["verts"] rot = Euler(euler).to_matrix() origin = Vector(loc) for v in verts: v.co = rot @ v.co + origin faces = {f for v in verts for f in v.link_faces} for f in faces: f.material_index = mat_idx return verts def add_rim(bm, loc, major, minor, mat_idx, euler=(0.0, 0.0, 0.0), n_major=18, n_minor=8): rings = [] for i in range(n_major): u = i * (2.0 * math.pi / n_major) ring = [] for j in range(n_minor): v = j * (2.0 * math.pi / n_minor) ring.append(bm.verts.new(( (major + minor * math.cos(v)) * math.cos(u), (major + minor * math.cos(v)) * math.sin(u), minor * math.sin(v), ))) rings.append(ring) bm.verts.ensure_lookup_table() for i in range(n_major): i2 = (i + 1) % n_major for j in range(n_minor): j2 = (j + 1) % n_minor face = bm.faces.new( (rings[i][j], rings[i2][j], rings[i2][j2], rings[i][j2]) ) face.material_index = mat_idx verts = [v for ring in rings for v in ring] rot = Euler(euler).to_matrix() origin = Vector(loc) for v in verts: v.co = rot @ v.co + origin return verts def add_square_band(bm, z, half, t, h, mat_idx): """Closed square collar in XY, extruded along Z. One manifold torus.""" z0 = z - h * 0.5 z1 = z + h * 0.5 inner = ( (half, half), (-half, half), (-half, -half), (half, -half), ) outer = ( (half + t, half + t), (-(half + t), half + t), (-(half + t), -(half + t)), (half + t, -(half + t)), ) def ring(zc, pts): return [bm.verts.new((p[0], p[1], zc)) for p in pts] i0 = ring(z0, inner) o0 = ring(z0, outer) i1 = ring(z1, inner) o1 = ring(z1, outer) def quad(a, b, c, d): face = bm.faces.new((a, b, c, d)) face.material_index = mat_idx return face for k in range(4): n = (k + 1) % 4 quad(i0[k], i0[n], i1[n], i1[k]) quad(o0[k], o1[k], o1[n], o0[n]) quad(i0[k], o0[k], o0[n], i0[n]) quad(i1[k], i1[n], o1[n], o1[k]) return i0 + o0 + i1 + o1 def face_area(me, poly): vs = [me.vertices[i].co for i in poly.vertices] if len(vs) < 3: return 0.0 v0 = vs[0] area = 0.0 for i in range(1, len(vs) - 1): area += (vs[i] - v0).cross(vs[i + 1] - v0).length * 0.5 return area def hygiene_audit(me): # Combinatorics match examples/mesh-hygiene-audit.audit (copied, not imported). nv, ne, nf = len(me.vertices), len(me.edges), len(me.polygons) ngons = sum(1 for p in me.polygons if len(p.vertices) > 4) areas = [face_area(me, p) for p in me.polygons] zero_area = sum(1 for a in areas if a <= AREA_EPS) bm = bmesh.new() try: bm.from_mesh(me) bm.verts.ensure_lookup_table() bm.edges.ensure_lookup_table() loose_v = sum(1 for v in bm.verts if len(v.link_edges) == 0) loose_e = sum(1 for e in bm.edges if len(e.link_faces) == 0) nonman = sum(1 for e in bm.edges if not e.is_manifold) ret = bmesh.ops.find_doubles(bm, verts=list(bm.verts), dist=DOUBLES_EPS) doubles = len(ret.get("targetmap") or {}) finally: bm.free() return { "nv": nv, "ne": ne, "nf": nf, "ngons": ngons, "loose_v": loose_v, "loose_e": loose_e, "nonman": nonman, "zero_area": zero_area, "doubles": doubles, "euler": nv - ne + nf, } def min_mat_distance(me, ia, ib): """Closest surface distance between two material islands via BVH.""" bm_a = bmesh.new() bm_b = bmesh.new() try: bm_a.from_mesh(me) bm_b.from_mesh(me) bm_a.faces.ensure_lookup_table() bm_b.faces.ensure_lookup_table() drop_a = [f for f in bm_a.faces if f.material_index != ia] drop_b = [f for f in bm_b.faces if f.material_index != ib] if drop_a: bmesh.ops.delete(bm_a, geom=drop_a, context="FACES") if drop_b: bmesh.ops.delete(bm_b, geom=drop_b, context="FACES") if not bm_a.faces or not bm_b.faces: return 1e9 tree = BVHTree.FromBMesh(bm_b) best = 1e9 for v in bm_a.verts: hit = tree.find_nearest(v.co) if hit[0] is None: continue best = min(best, hit[3]) for f in bm_a.faces: hit = tree.find_nearest(f.calc_center_median()) if hit[0] is None: continue best = min(best, hit[3]) return best finally: bm_a.free() bm_b.free() def pack_uvs(bm, margin=0.08): uv = bm.loops.layers.uv.new("UVMap") faces = list(bm.faces) n = len(faces) cols = max(1, math.ceil(math.sqrt(n))) rows = max(1, math.ceil(n / cols)) cell_w = 1.0 / cols cell_h = 1.0 / rows pad_u = margin * cell_w * 0.5 pad_v = margin * cell_h * 0.5 usable_w = cell_w - 2.0 * pad_u usable_h = cell_h - 2.0 * pad_v for i, face in enumerate(faces): col = i % cols row = i // cols nrm = face.normal ax = abs(nrm.x) ay = abs(nrm.y) az = abs(nrm.z) coords = [] for loop in face.loops: co = loop.vert.co if az >= ax and az >= ay: coords.append((co.x, co.y)) elif ax >= ay: coords.append((co.y, co.z)) else: coords.append((co.x, co.z)) xs = [c[0] for c in coords] ys = [c[1] for c in coords] minx, maxx = min(xs), max(xs) miny, maxy = min(ys), max(ys) dx = max(maxx - minx, 1e-8) dy = max(maxy - miny, 1e-8) origin_u = col * cell_w + pad_u origin_v = row * cell_h + pad_v for loop, (x, y) in zip(face.loops, coords): loop[uv].uv = ( origin_u + (x - minx) / dx * usable_w, origin_v + (y - miny) / dy * usable_h, ) def build_hitching_post_mesh(name, bevel_offset, bevel_segments): bm = bmesh.new() try: wood = [] half = POST_W / 2.0 cap_r = half * math.sqrt(2.0) wood.extend( add_box( bm, (0.0, 0.0, POST_H / 2.0), (POST_W, POST_W, POST_H), WOOD_IDX, ) ) # Pyramid whose base vertices land on the post corners, then embed # 2mm so the cap/post plane cannot z-fight. wood.extend( add_cone( bm, (0.0, 0.0, POST_H + CAP_H / 2.0 - CAP_EMBED), cap_r, 0.008, CAP_H, 4, WOOD_IDX, euler=(0.0, 0.0, math.pi / 4.0), ) ) stub = ARM_L / 2.0 - half tenon_y = ARM_Y * TENON_SCALE tenon_z = ARM_ZTH * TENON_SCALE wood.extend( add_box( bm, (0.0, 0.0, ARM_Z), (POST_W + 0.012, tenon_y, tenon_z), WOOD_IDX, ) ) wood.extend( add_box( bm, (half + stub / 2.0, 0.0, ARM_Z), (stub, ARM_Y, ARM_ZTH), WOOD_IDX, ) ) wood.extend( add_box( bm, (-(half + stub / 2.0), 0.0, ARM_Z), (stub, ARM_Y, ARM_ZTH), WOOD_IDX, ) ) if bevel_offset > 0.0: edges = list({e for v in wood for e in v.link_edges if v.is_valid}) ret = bmesh.ops.bevel( bm, geom=edges, offset=bevel_offset, segments=bevel_segments, profile=0.5, affect="EDGES", clamp_overlap=True, ) for f in ret.get("faces") or []: f.material_index = WOOD_IDX # Shoe is a collar whose inner faces sit on the post, not a solid plate # the post punches through. add_square_band(bm, SHOE_H / 2.0, half - 0.002, SHOE_T, SHOE_H, METAL_IDX) for z in BAND_ZS: add_square_band(bm, z, half - 0.002, BAND_T, BAND_H, METAL_IDX) arm_y_face = -(ARM_Y / 2.0) for sx in (-ARM_L * 0.32, ARM_L * 0.32): # Eye on the -Y arm face; hitching ring threads it (YZ vs XZ). add_rim( bm, (sx, arm_y_face + EYE_MINOR * 0.25, ARM_Z), EYE_MAJOR, EYE_MINOR, METAL_IDX, euler=(math.pi / 2.0, 0.0, 0.0), n_major=14, n_minor=7, ) add_rim( bm, ( sx, arm_y_face - RING_MAJOR * 0.55, ARM_Z - RING_MAJOR * 0.28, ), RING_MAJOR, RING_MINOR, METAL_IDX, euler=(0.0, math.pi / 2.0, 0.0), n_major=18, n_minor=8, ) bmesh.ops.remove_doubles(bm, verts=list(bm.verts), dist=DOUBLES_EPS) bm.faces.ensure_lookup_table() degen = [f for f in bm.faces if f.calc_area() <= AREA_EPS] if degen: bmesh.ops.delete(bm, geom=degen, context="FACES") xs = [v.co.x for v in bm.verts] ys = [v.co.y for v in bm.verts] zs = [v.co.z for v in bm.verts] rcx = 0.5 * (min(xs) + max(xs)) rcy = 0.5 * (min(ys) + max(ys)) zmin = min(zs) for v in bm.verts: v.co.x -= rcx v.co.y -= rcy v.co.z -= zmin if v.co.z < 0.0: v.co.z = 0.0 pack_uvs(bm) bmesh.ops.recalc_face_normals(bm, faces=list(bm.faces)) for face in bm.faces: if face.material_index == METAL_IDX: face.smooth = True else: face.smooth = False for edge in bm.edges: if not edge.is_manifold or len(edge.link_faces) != 2: continue if edge.calc_face_angle() > math.radians(35.0): edge.smooth = False me = bpy.data.meshes.new(name) bm.to_mesh(me) me.update() for poly in me.polygons: poly.use_smooth = poly.material_index == METAL_IDX finally: bm.free() out = bpy.data.objects.new(name, me) bpy.context.collection.objects.link(out) return out def principled(name, color, metallic, roughness, noise_scale=0.0, wear=None): mat = bpy.data.materials.new(name) mat.use_nodes = True nt = mat.node_tree bsdf = nt.nodes["Principled BSDF"] bsdf.inputs["Base Color"].default_value = color bsdf.inputs["Metallic"].default_value = metallic bsdf.inputs["Roughness"].default_value = roughness if noise_scale > 0.0 and wear is not None: tex = nt.nodes.new("ShaderNodeTexNoise") tex.inputs["Scale"].default_value = noise_scale tex.inputs["Detail"].default_value = 6.0 mix = nt.nodes.new("ShaderNodeMix") mix.data_type = "RGBA" mix.inputs["A"].default_value = color mix.inputs["B"].default_value = wear fac = mix.inputs.get("Factor") or mix.inputs.get("Fac") nt.links.new(tex.outputs["Fac"], fac) nt.links.new(mix.outputs["Result"], bsdf.inputs["Base Color"]) return mat def assign_slots(obj, wood, metal): mats = obj.data.materials wanted = (wood, metal) for i, mat in enumerate(wanted): if i < len(mats): mats[i] = mat else: mats.append(mat) def world_bbox(obj): corners = [obj.matrix_world @ Vector(c) for c in obj.bound_box] xs = [c.x for c in corners] ys = [c.y for c in corners] zs = [c.z for c in corners] return (min(xs), min(ys), min(zs), max(xs), max(ys), max(zs)) def uv_stats(mesh): uv = mesh.uv_layers.active if uv is None: return 0.0, 0.0, 1.0, 1.0, 0, 1.0 data = uv.data us = [loop.uv[0] for loop in data] vs = [loop.uv[1] for loop in data] aabbs = [] for poly in mesh.polygons: pu = [data[i].uv[0] for i in poly.loop_indices] pv = [data[i].uv[1] for i in poly.loop_indices] aabbs.append((min(pu), min(pv), max(pu), max(pv))) overlap = 0.0 for i in range(len(aabbs)): a = aabbs[i] for j in range(i + 1, len(aabbs)): b = aabbs[j] x0 = max(a[0], b[0]) y0 = max(a[1], b[1]) x1 = min(a[2], b[2]) y1 = min(a[3], b[3]) overlap += max(0.0, x1 - x0) * max(0.0, y1 - y0) return min(us), min(vs), max(us), max(vs), overlap, len(aabbs) def make_lod(obj, name, ratio, skip_decimate): mesh = obj.data.copy() lod = bpy.data.objects.new(name, mesh) lod.matrix_world = obj.matrix_world.copy() bpy.context.scene.collection.objects.link(lod) if not skip_decimate and 0.0 < ratio < 1.0: mod = lod.modifiers.new("DecimateBudget", "DECIMATE") mod.decimate_type = "COLLAPSE" mod.ratio = ratio return lod def convex_hull_collider(obj, name): mesh = bpy.data.meshes.new(name) bm = bmesh.new() try: bm.from_mesh(obj.data) result = bmesh.ops.convex_hull(bm, input=list(bm.verts)) interior = result.get("geom_interior") or [] unused = result.get("geom_unused") or [] if interior: bmesh.ops.delete(bm, geom=interior, context="VERTS") if unused: bmesh.ops.delete(bm, geom=unused, context="VERTS") bm.to_mesh(mesh) mesh.update() finally: bm.free() collider = bpy.data.objects.new(name, mesh) bpy.context.collection.objects.link(collider) collider.matrix_world = obj.matrix_world.copy() return collider def setup_bake_image(obj, target_mat, size=BAKE_RES): if not obj.data.uv_layers: return None, None img = bpy.data.images.new("HitchPostNrm", size, size, alpha=True, float_buffer=False) img.colorspace_settings.name = "Non-Color" nodes = target_mat.node_tree.nodes tex = nodes.new("ShaderNodeTexImage") tex.image = img nodes.active = tex tex.select = True obj.active_material_index = WOOD_IDX return img, tex def bake_normal(high, low): scene = bpy.context.scene scene.render.engine = "CYCLES" scene.cycles.device = "CPU" scene.cycles.samples = 1 scene.cycles.use_denoising = False deselect_all() high.select_set(True) low.select_set(True) bpy.context.view_layer.objects.active = low return bpy.ops.object.bake( type="NORMAL", use_selected_to_active=True, cage_extrusion=CAGE_EXTRUSION, use_cage=False, normal_space="TANGENT", margin=4, margin_type="ADJACENT_FACES", use_clear=True, target="IMAGE_TEXTURES", ) def export_unity(path, objects): deselect_all() for ob in objects: ob.select_set(True) bpy.context.view_layer.objects.active = objects[0] bpy.ops.export_scene.gltf( filepath=path, use_selection=True, export_yup=True, export_apply=True, export_draco_mesh_compression_enable=False, export_animations=False, ) def check(skip_decimate, lift_z=False): bpy.ops.wm.read_factory_settings(use_empty=True) low = build_hitching_post_mesh("HitchPostLow", bevel_offset=0.008, bevel_segments=2) high = build_hitching_post_mesh("HitchPostHigh", bevel_offset=0.008, bevel_segments=4) wood = principled( "HitchPostWood", (0.36, 0.19, 0.07, 1.0), 0.0, 0.62, noise_scale=11.0, wear=(0.24, 0.13, 0.05, 1.0), ) metal = principled("HitchPostIron", (0.12, 0.125, 0.135, 1.0), 1.0, 0.42) assign_slots(low, wood, metal) assign_slots(high, wood, metal) if lift_z: for v in low.data.vertices: v.co.z += LIFT_Z low.data.update() if low.data is None or len(low.data.polygons) < 6: return fail("hitching post mesh did not build", 3), None, None, None, None, None base_tris = triangle_count(low.data) mats = [s for s in low.data.materials if s is not None] nmat = len(mats) distinct_mats = len({id(s) for s in mats}) idx_counts = {} for poly in low.data.polygons: idx_counts[poly.material_index] = idx_counts.get(poly.material_index, 0) + 1 print(f"measured mat_index_counts={idx_counts}") u0, v0, u1, v1, overlap, nfaces = uv_stats(low.data) bb = world_bbox(low) size_x = bb[3] - bb[0] size_y = bb[4] - bb[1] size_z = bb[5] - bb[2] img, tex = setup_bake_image(low, wood) if img is None: return fail("hitching post has no UV layer", 3), None, None, None, None, None bake_result = bake_normal(high, low) lod1 = make_lod(low, "HitchPostLOD1", LOD1_TARGET, skip_decimate) lod2 = make_lod(low, "HitchPostLOD2", LOD2_TARGET, skip_decimate) bpy.context.view_layer.update() lod1_tris = evaluated_triangle_count(lod1) lod2_tris = evaluated_triangle_count(lod2) r1 = lod1_tris / base_tris if base_tris else 0.0 r2 = lod2_tris / base_tris if base_tris else 0.0 collider_src = build_hitching_post_mesh( "HitchPostColSrc", bevel_offset=0.0, bevel_segments=1 ) collider = convex_hull_collider(collider_src, "HitchPostCollider") bpy.data.objects.remove(collider_src, do_unlink=True) col_tris = triangle_count(collider.data) export_path = os.path.join( tempfile.gettempdir(), f"bdt_hitching_post_{os.getpid()}.glb", ) if os.path.exists(export_path): os.remove(export_path) export_unity(export_path, [low, collider]) export_size = os.path.getsize(export_path) if os.path.isfile(export_path) else 0 print(f"blender={tuple(bpy.app.version)} skip_decimate={skip_decimate}") print( f"measured base_tris={base_tris} lod1_tris={lod1_tris} " f"lod2_tris={lod2_tris} r1={r1:.4f} r2={r2:.4f}" ) print( f"measured nmat={nmat} uv=({u0:.4f},{v0:.4f})-({u1:.4f},{v1:.4f}) " f"overlap={overlap:.6f} nfaces={nfaces}" ) print( f"measured bbox=({size_x:.4f},{size_y:.4f},{size_z:.4f}) " f"outer={OUTER_SIZE} zmin={bb[2]:.4f}" ) hyg = hygiene_audit(low.data) gap = min_mat_distance(low.data, METAL_IDX, WOOD_IDX) print( f"measured collider_tris={col_tris} bake={bake_result} " f"bake_has_data={img.has_data} export_bytes={export_size}" ) print( f"measured hygiene loose_v={hyg['loose_v']} loose_e={hyg['loose_e']} " f"nonman={hyg['nonman']} zero_area={hyg['zero_area']} " f"doubles={hyg['doubles']} ngons={hyg['ngons']} euler={hyg['euler']}" ) print(f"measured wood_metal_gap={gap:.5f} zmin={bb[2]:.6f}") if not (BASE_TRIS_MIN <= base_tris <= BASE_TRIS_MAX): return fail( f"base tris {base_tris} not in [{BASE_TRIS_MIN}, {BASE_TRIS_MAX}]", 4, ), None, None, None, None, None if nmat != MATERIAL_COUNT or distinct_mats != MATERIAL_COUNT: return fail( f"material slots {nmat} distinct {distinct_mats} != {MATERIAL_COUNT}", 5, ), None, None, None, None, None if idx_counts.get(METAL_IDX, 0) < METAL_FACES_MIN: return fail( f"metal faces {idx_counts.get(METAL_IDX, 0)} < {METAL_FACES_MIN}", 5, ), None, None, None, None, None if idx_counts.get(WOOD_IDX, 0) < WOOD_FACES_MIN: return fail( f"wood faces {idx_counts.get(WOOD_IDX, 0)} < {WOOD_FACES_MIN}", 5, ), None, None, None, None, None if u0 < -UV_EPS or v0 < -UV_EPS or u1 > 1.0 + UV_EPS or v1 > 1.0 + UV_EPS: return fail( f"UVs outside 0..1: ({u0:.4f},{v0:.4f})-({u1:.4f},{v1:.4f})", 6, ), None, None, None, None, None if overlap > UV_OVERLAP_MAX: return fail( f"UV AABB overlap {overlap:.6f} > {UV_OVERLAP_MAX}", 7, ), None, None, None, None, None if ( abs(size_x - OUTER_SIZE[0]) > BBOX_TOL or abs(size_y - OUTER_SIZE[1]) > BBOX_TOL or abs(size_z - OUTER_SIZE[2]) > BBOX_TOL ): return fail( f"bbox ({size_x:.4f},{size_y:.4f},{size_z:.4f}) " f"off outer {OUTER_SIZE}", 8, ), None, None, None, None, None if not (LOD1_RATIO_MIN <= r1 <= LOD1_RATIO_MAX): return fail( f"LOD1 ratio {r1:.4f} not in [{LOD1_RATIO_MIN}, {LOD1_RATIO_MAX}] " "(--skip-decimate is the designed fail)", 9, ), None, None, None, None, None if not (LOD2_RATIO_MIN <= r2 <= LOD2_RATIO_MAX): return fail( f"LOD2 ratio {r2:.4f} not in [{LOD2_RATIO_MIN}, {LOD2_RATIO_MAX}]", 9, ), None, None, None, None, None if col_tris > COLLIDER_TRIS_MAX: return fail( f"collider tris {col_tris} > {COLLIDER_TRIS_MAX}", 11, ), None, None, None, None, None if bake_result != {"FINISHED"} or not img.has_data: return fail( f"bake failed result={bake_result} has_data={img.has_data}", 12, ), None, None, None, None, None if export_size <= 0: return fail("export file missing or empty", 13), None, None, None, None, None if ( hyg["loose_v"] or hyg["loose_e"] or hyg["nonman"] or hyg["zero_area"] or hyg["doubles"] or hyg["ngons"] ): return fail( f"hygiene loose_v={hyg['loose_v']} loose_e={hyg['loose_e']} " f"nonman={hyg['nonman']} zero_area={hyg['zero_area']} " f"doubles={hyg['doubles']} ngons={hyg['ngons']}", 15, ), None, None, None, None, None if abs(bb[2]) > ZMIN_EPS: return fail( f"zmin {bb[2]:.6f} not within {ZMIN_EPS} of 0 " "(--lift-z is the designed fail)", 16, ), None, None, None, None, None if gap > GAP_MAX: return fail( f"wood-metal gap {gap:.5f} > {GAP_MAX}", 17, ), None, None, None, None, None return 0, low, high, wood, tex, collider def wire_normal(mat, tex): nt = mat.node_tree bsdf = nt.nodes["Principled BSDF"] nrm = nt.nodes.new("ShaderNodeNormalMap") nrm.inputs["Strength"].default_value = 1.0 nt.links.new(tex.outputs["Color"], nrm.inputs["Color"]) nt.links.new(nrm.outputs["Normal"], bsdf.inputs["Normal"]) def render_still(low, wood, tex, path, engine): scene = bpy.context.scene wire_normal(wood, tex) for ob in list(scene.objects): if ob.type == "MESH" and ob != low: ob.hide_render = True ob.hide_viewport = True low.rotation_euler.z = math.radians(-18.0) low.rotation_euler.x = math.radians(0.0) floor_me = bpy.data.meshes.new("Floor") bm = bmesh.new() try: bmesh.ops.create_grid(bm, x_segments=1, y_segments=1, size=14.0) bm.to_mesh(floor_me) finally: bm.free() fmat = bpy.data.materials.new("Floor") fmat.use_nodes = True fb = fmat.node_tree.nodes["Principled BSDF"] fb.inputs["Base Color"].default_value = (0.03, 0.032, 0.037, 1.0) fb.inputs["Roughness"].default_value = 0.7 floor_me.materials.append(fmat) floor = bpy.data.objects.new("Floor", floor_me) scene.collection.objects.link(floor) wall = bpy.data.objects.new("Wall", floor_me.copy()) wall.location = (0.0, 8.5, 0.0) wall.rotation_euler = (math.radians(90), 0.0, 0.0) scene.collection.objects.link(wall) world = bpy.data.worlds.new("World") world.use_nodes = True world.node_tree.nodes["Background"].inputs["Color"].default_value = ( 0.02, 0.021, 0.025, 1.0, ) scene.world = world def light(name, loc, energy, size, col, rot): ld = bpy.data.lights.new(name, "AREA") ld.energy = energy ld.size = size ld.color = col ob = bpy.data.objects.new(name, ld) ob.location = loc ob.rotation_euler = tuple(math.radians(a) for a in rot) scene.collection.objects.link(ob) light("Key", (-3.6, -5.0, 5.4), 660.0, 4.0, (1.0, 0.94, 0.86), (50, 0, -36)) light("Fill", (5.0, -3.4, 2.4), 46.0, 8.0, (0.72, 0.82, 1.0), (62, 0, 50)) light("Wedge", (2.2, 4.0, 3.8), 600.0, 5.5, (1.0, 0.70, 0.40), (-70, 0, 198)) cam_data = bpy.data.cameras.new("Cam") cam_data.lens = 50.0 cam = bpy.data.objects.new("Cam", cam_data) cam.location = (2.25, -3.12, 1.22) scene.collection.objects.link(cam) aim = bpy.data.objects.new("Aim", None) aim.location = (0.0, 0.0, 0.63) scene.collection.objects.link(aim) con = cam.constraints.new("TRACK_TO") con.target = aim con.track_axis = "TRACK_NEGATIVE_Z" con.up_axis = "UP_Y" scene.camera = cam scene.render.engine = "CYCLES" if engine == "cycles" else eevee_engine_id() if engine == "cycles": scene.cycles.samples = 32 scene.cycles.device = "CPU" else: try: scene.eevee.taa_render_samples = 64 except AttributeError: pass scene.render.resolution_x = 1280 scene.render.resolution_y = 720 scene.render.image_settings.file_format = ( "WEBP" if path.lower().endswith(".webp") else "PNG" ) if path.lower().endswith(".webp"): scene.render.image_settings.quality = 90 scene.render.filepath = path scene.view_settings.view_transform = "Standard" fcode = gallery_framing.check_framing( scene, cam, hero=[low], elements=[low], stage=[floor, wall], ) if fcode: return fcode bpy.ops.render.render(write_still=True) if not (os.path.exists(path) and os.path.getsize(path) > 0): return fail("render produced no file", 14) return 0 def main(): argv = sys.argv[sys.argv.index("--") + 1:] if "--" in sys.argv else [] p = argparse.ArgumentParser() p.add_argument("--output", default=None) p.add_argument("--engine", default="eevee", choices=("eevee", "cycles")) p.add_argument( "--skip-decimate", action="store_true", help="falsification: skip the LOD DECIMATE stage", ) p.add_argument( "--lift-z", action="store_true", help="falsification: lift the mesh so zmin fails the grounded budget", ) args = p.parse_args(argv) code, low, _high, wood, tex, _col = check(args.skip_decimate, lift_z=args.lift_z) if code: return code if args.output: rcode = render_still(low, wood, tex, os.path.abspath(args.output), args.engine) if rcode: return rcode print(f"rendered still {args.output}") print("hitching-post OK") return 0 if __name__ == "__main__": try: sys.exit(main()) except Exception as e: traceback.print_exc() print(f"FATAL: {e}", file=sys.stderr) sys.exit(1)